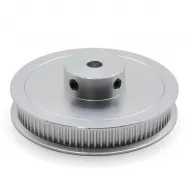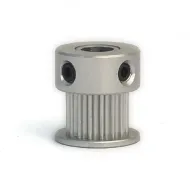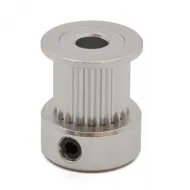


- Stock: 134
- Model: GT2-16T-ID5-10mm
Model:

16T - belt 6mm

16Z - 9 and 10mm belt

16T POWGE- belt 6mm POWGE

16Z - belt 10mm POWGE

20T - belt 6mm

20T - 9 and 10mm belt

20Z - belt 6mm POWGE

20Z - belt 10mm POWGE

36T - belt 6mm

80T POWGE 6mm belt

80T - belt 6mm
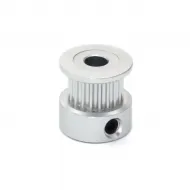
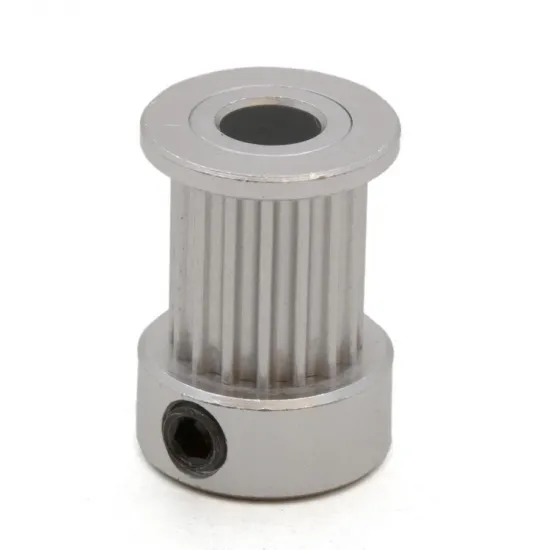
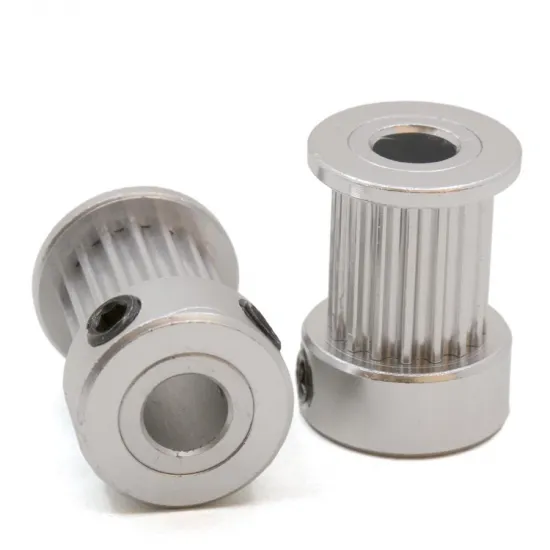
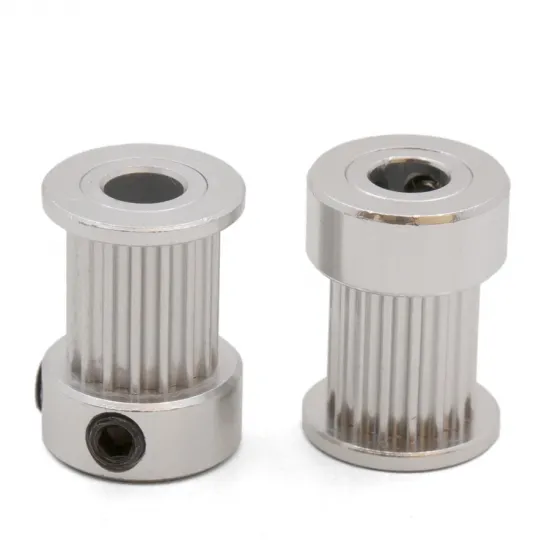
GT2 16-tooth drive pulley for 9 and 10 mm belts, made of aluminium and designed to be secured to a 5 mm shaft with two grub screws.
Unlike a bearing-mounted idler, this pulley is locked to the shaft and directly transmits motor rotation to the belt. Its 16-tooth format provides a compact transmission and greater linear resolution than a 20-tooth pulley using the same motor.
Features and dimensions
- Type: toothed drive pulley.
- Profile: GT2 / 2GT, 2 mm pitch.
- Number of teeth: 16.
- Compatible belt widths: 9 and 10 mm.
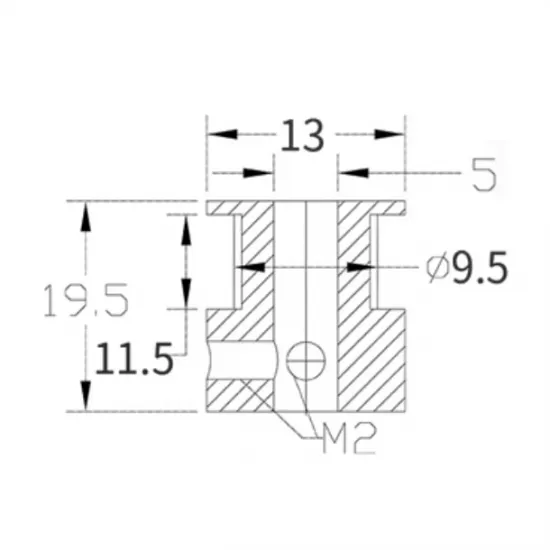
- Inner diameter: Ø5 mm.
- Approximate toothed section diameter: Ø9.5 mm.
- Flange diameter: approximately Ø13 mm.
- Usable width shown in the drawing: approximately 11.5 mm.
- Overall height: approximately 19.5 mm.
- Fastening: two radial M2 grub screws.
- Material: aluminium.
Motor installation
The 5 mm bore is dimensionally compatible with many NEMA 17 stepper motors using a Ø5 mm shaft. Check the actual shaft diameter, as NEMA 17 defines the motor flange size rather than the shaft diameter.
Whenever possible, position one grub screw against the flat section of the motor shaft. Tighten both screws progressively and check that the pulley remains centred, does not wobble and is aligned with the rest of the belt path.
The pulley teeth should engage with the toothed side of the belt. The flanges provide guidance, but continuous lateral contact indicates that the pulley, motor or mechanism is misaligned.
Compatibility
It is compatible with 9 and 10 mm GT2 belts, including our wear-resistant 9 mm GT2 belt, 9 mm POWGE GT2 RF belt, wear-resistant 10 mm GT2 belt and 10 mm POWGE GT2 belt.
It can be used in 3D printers, CNC machines and custom CoreXY systems jointly specifying a 16-tooth pulley, a 9 or 10 mm belt and a 5 mm shaft.
It is not a direct replacement for common Voron configurations using 6 mm belts unless the machine has been specifically modified for a wider belt system.
For a 20-tooth transmission, see the GT2 20T drive pulley for 9 and 10 mm belts. For a branded alternative, see the POWGE GT2 16T pulley for 10 mm belts, checking the selected bore diameter first.
Firmware configuration
Replacing another 16-tooth pulley should not require a steps-per-millimetre change when the motor, microstepping, transmission and belt pitch remain unchanged. Changing the tooth count requires recalculation.
Formula for a directly driven axis:
steps/mm = (motor steps per revolution × microsteps) ÷ (pulley teeth × belt pitch)
With a 1.8° motor, 200 full steps per revolution, 16 microsteps and a 2 mm GT2 belt, a 16-tooth pulley gives a theoretical value of 100 steps/mm. Check this value when gear reduction, different microstepping or controller-specific settings are used.
- Marlin: configure the axis steps using
DEFAULT_AXIS_STEPS_PER_UNITorM92. Save withM500when EEPROM is enabled. - Klipper: for direct GT2 drive, the theoretical value is
rotation_distance: 32, as 16 teeth × 2 mm equals 32 mm per revolution. Also checkgear_ratiowhen reduction is used. - RepRapFirmware: enter the calculated steps per millimetre using
M92inconfig.g.
After any change, verify the actual axis travel and only apply corrections based on a reliable measurement.
Contents: 1 drive pulley with two grub screws.