

- Stock: 18
- Model: 17HS8401
Model:

17HS2408

17HS3401

17HS4401

17HS4401s-09

17HS8401

17hs8401S-09

17HS6401

17HS6401s-09
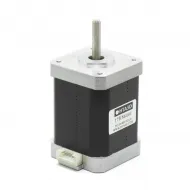
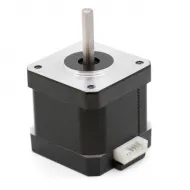
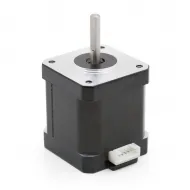
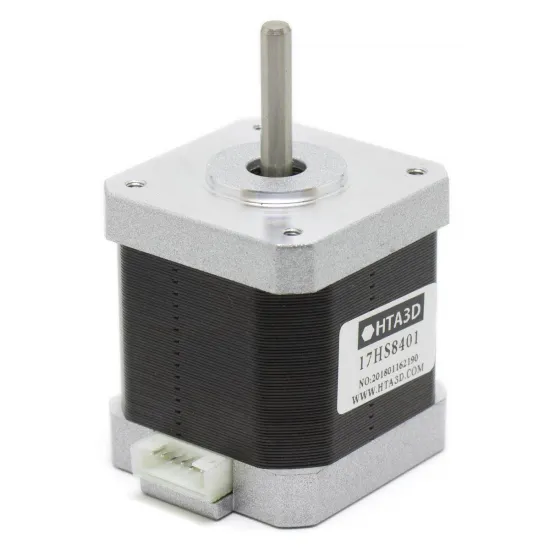
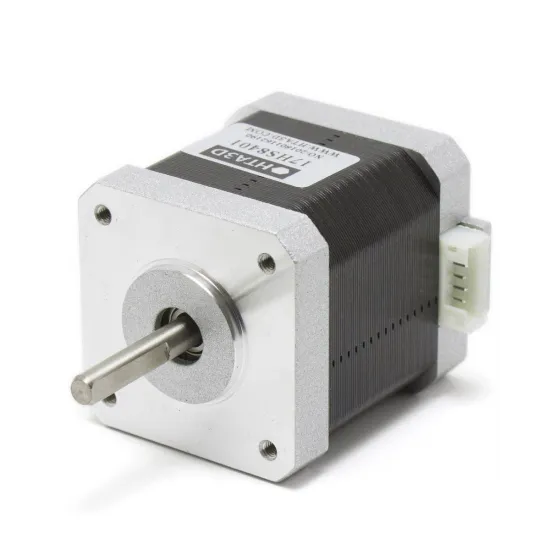
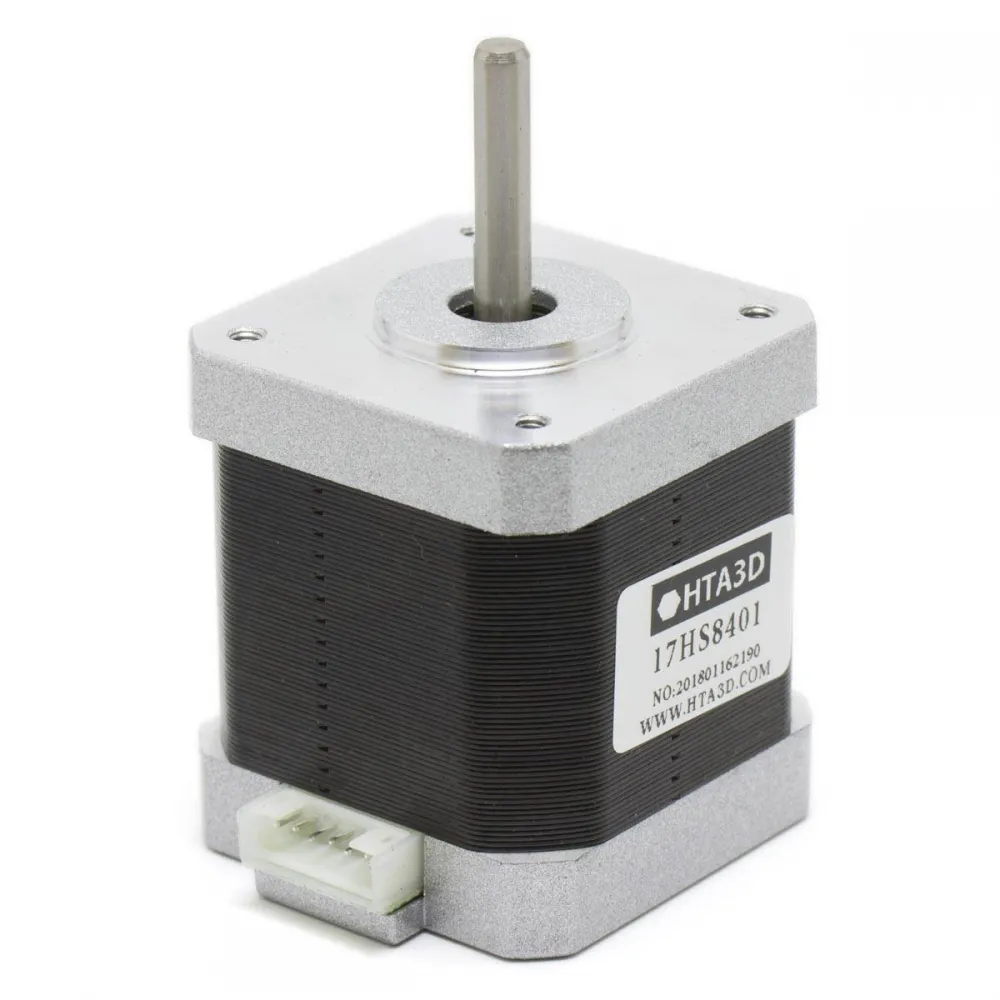
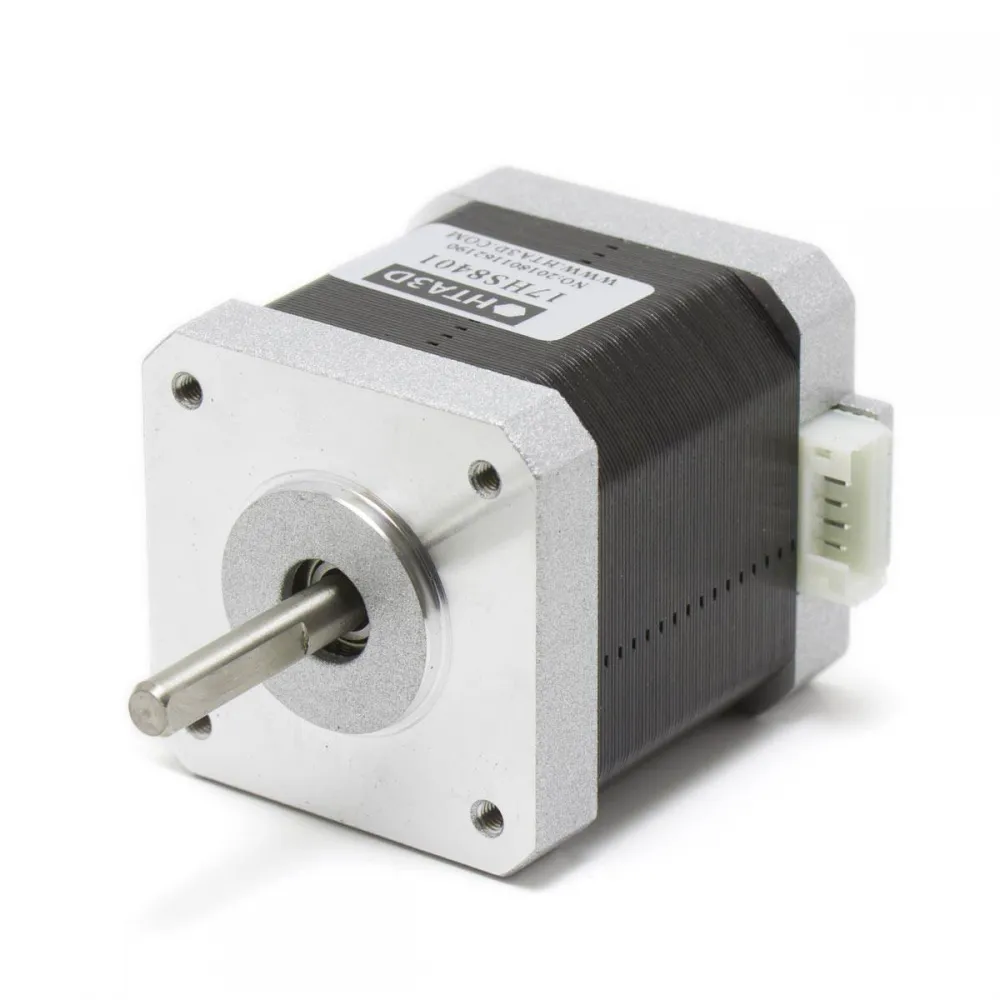
The 17HS8401 is a bipolar NEMA 17 stepper motor with a long 42 × 48mm body, a 1.8° step angle and a minimum 52N·cm holding torque. It is intended for axes and mechanisms requiring more torque margin than a 40mm-long NEMA 17 while retaining the standard 42mm front interface.
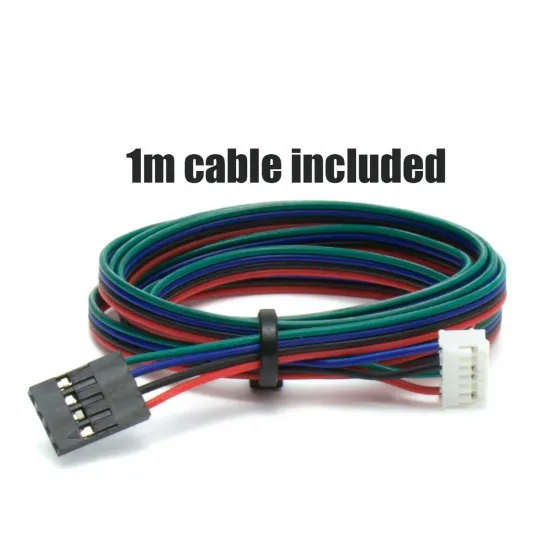
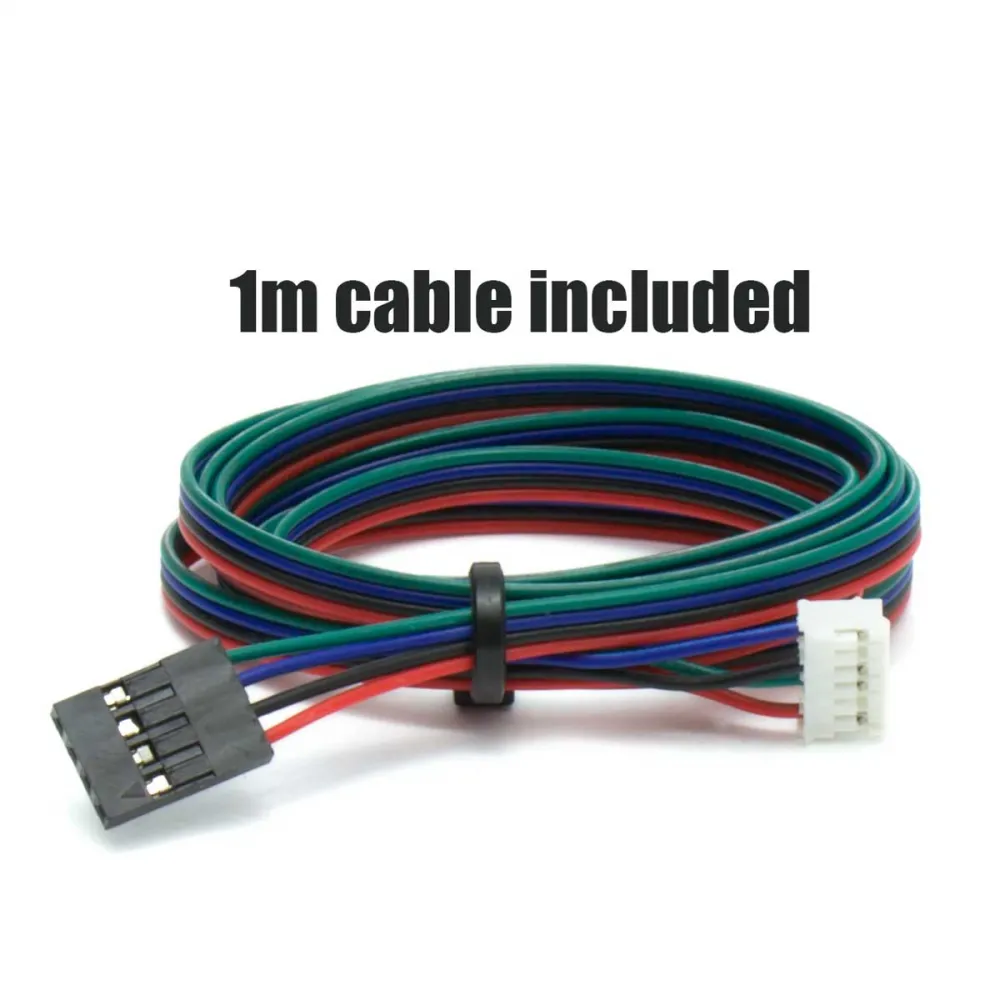
Its front 5mm D-shaped shaft helps set screws secure pulleys and couplings. An approximately one-metre cable is included for connection to a compatible controller or stepper driver.
Electrical specifications
| Parameter | Nominal value | Meaning |
|---|---|---|
| Type | Bipolar, 2 phases and 4 wires | Requires a current-regulated bipolar driver |
| Step angle | 1.8° | 200 full steps per revolution |
| Rated current | 1.7A per phase | Reference limit for driver adjustment, not fixed PSU consumption |
| Phase resistance | 1.8Ω | Approximately 3.06V resistive equivalent at 1.7A |
| Phase inductance | 3.2mH | Influences current rise and available torque at speed |
| Holding torque | 52N·cm min. (0.52N·m) | Static, energised torque; it is not the available running torque |
| Detent torque | 2.6N·cm max. | Magnetic resistance with power removed |
| Rotor inertia | 68g·cm² | Affects acceleration and deceleration |
| Nominal weight | Approx. 350g | Excluding cable and packaging |
Do not connect it directly to a 12V or 24V power supply. Those voltages may feed the driver, which regulates winding current by switching. Powering the motor without current limiting can overheat and damage it.
Dimensions and mounting
| Dimension | Nominal value |
|---|---|
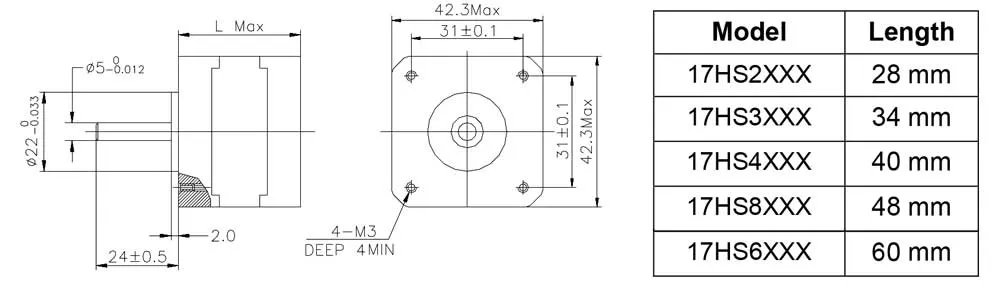
| Front face | 42.3 × 42.3mm maximum |
| Body length | 48mm |
| Mounting pattern | 31 ±0.1mm square hole spacing |
| Mounting threads | 4 × M3, approximately 4mm minimum usable depth |
| Locating boss | 22mm diameter and 2mm high |
| Shaft | 5mm diameter, D-shaped flat |
| Front shaft length | 24 ±0.5mm from the front face |
It can be fitted to the NEMA 17 L-shaped mounting bracket when there is enough clearance for its 48mm body and the application does not exceed the bracket's rigidity. Use M3 screws of a suitable length: an excessively long screw may enter the motor.
For 6mm belt drives it can be paired with the 20-tooth GT2 drive pulley with a 5mm bore. Whenever possible, place one pulley set screw against the shaft flat.
Compatibility: when it can replace another motor
It is a reasonable replacement for a 42-48, 1.8° motor when all of the following match:
- NEMA 17 front face and four M3 mounting threads on a 31mm square pattern.
- Sufficient clearance for the 48mm body and its connector.
- Compatible 5mm front shaft, 24mm shaft length and flat position.
- A driver capable of regulating the required current with adequate cooling.
- Two bipolar windings with a correctly identified pinout.
- Adequate dynamic torque, speed and acceleration for the actual load.
This reference was used in selected historical HTA3D 3DSteel configurations. For repairs, check the installed motor and the exact machine revision because the equipment may have changed over time.
It may also be integrated into P3Steel, Prusa i3 derivatives, CoreXY machines, plotters, laser engravers, robots and small CNC systems when their design specifies a NEMA 17 42-48 with these characteristics. It is not an automatic replacement for an Ender, Original Prusa, Voron or other commercial machine merely because it uses NEMA 17 motors.
Consider moving mass when the motor travels with an axis. Its approximately 350g body provides more holding torque than a shorter motor but can limit acceleration on a moving carriage. For a more compact alternative, see the 40mm, 40N·cm NEMA 17 17HS4401. If the project requires a 0.9° motor with 400 full steps per revolution, see the 0.9° 42-48 NEMA 17 and verify its electrical requirements separately.
Identifying the windings and connecting the motor
The supplied cable has four conductors, but wire colours are not a universal standard. A controller may use the same connector with a different pin order.
- Disconnect both the power supply and USB cable completely.
- Use a multimeter in continuity or resistance mode to find the two pairs. Two wires from the same winding show continuity and low resistance.
- Connect one complete pair to driver outputs A1/A2 and the other pair to B1/B2.
- If the motor vibrates without turning, switch off immediately and check that one wire from each winding has not been mixed together.
- Reverse direction in firmware. Alternatively, with all power removed, swap the two wires belonging to one winding only.
Setting driver current
More current provides more torque margin but also increases motor and driver temperature. The correct setting depends on the axis, load, acceleration, cooling, supply voltage and the way in which the driver expresses current. A value that works on another printer may not be appropriate.
The motor can be used with A4988, DRV8825 or TMC drivers that provide sufficient regulated current. On modules adjusted by a potentiometer, the VREF formula depends on the sense resistor and exact module revision: there is no universal VREF value. For UART adjustment and diagnostics, see the current BIGTREETECH TMC2209.
Marlin with a configurable TMC driver
Marlin specifies X_CURRENT, Y_CURRENT, Z_CURRENT and E0_CURRENT in mA RMS. Its documentation states that peak current is approximately RMS × 1.414, so 1.7A peak is equivalent to about 1.20A RMS.
A conservative starting point on a typical 3D printer is 800-1000mA RMS. Increase it only if more torque or reliability is required and motor and driver temperatures remain acceptable. Example for the X axis:
#define X_CURRENT 900A compatible TMC can also be tested temporarily with M906 X900. Save with M500 only after validating the setting and when EEPROM is enabled. Replace X with the actual axis.
Klipper with a configurable TMC driver
Klipper uses RMS amperes for run_current. A cautious starting example for a properly cooled TMC2209 is:
[tmc2209 stepper_x]
run_current: 0.90
It can also be tested temporarily with SET_TMC_CURRENT STEPPER=stepper_x CURRENT=0.90. Monitor missed steps, motor temperature and driver warnings. Klipper recommends omitting hold_current unless there is a specific need because current transitions may cause small movements.
RepRapFirmware
RepRapFirmware uses M906 to configure peak current in mA. Duet3D generally recommends starting at 60-85% of the motor's rated current; for 1.7A this is approximately 1020-1445mA. A conservative example for X is:
M906 X1200 I30Place the final validated value in config.g. When using an external driver, M906 may not control its current and the adjustment must be made on the driver itself.
Steps, microsteps and transmission
The motor has 200 full steps per revolution. At 16 microsteps the driver generates 3200 electrical positions per revolution, but microstepping mainly improves smoothness and noise. It does not multiply usable mechanical accuracy or positioning torque by sixteen.
| Direct transmission | Travel per revolution | Marlin / RRF at 16 µsteps | Klipper |
|---|---|---|---|
| GT2, 20 teeth, 2mm pitch | 40mm | 80 steps/mm | full_steps_per_rotation: 200rotation_distance: 40 |
| TR8×8 lead screw | 8mm | 400 steps/mm | full_steps_per_rotation: 200rotation_distance: 8 |
These are theoretical values and apply only without a gearbox and when the pulley, belt pitch, lead-screw lead and microstep setting all match. Maximum acceleration and speed must be established by testing the complete machine because motor torque decreases as speed rises.
It is for you if
- You need a bipolar 42-48 NEMA 17 with a 1.8° step angle and 5mm front shaft.
- Your mechanism requires up to 52N·cm holding torque and accepts a 48mm body.
- You have a current-regulated driver and can verify winding pairs, pinout and cooling.
- You need to drive a belt, lead screw, remote extruder or light CNC mechanism using a compatible transmission.
It is not for you if
- You need a plug-and-play replacement based only on the fact that your machine uses NEMA 17 motors.
- You require a 0.9° motor, dual shaft, integrated lead screw, encoder or gearbox.
- The motor must travel on a very light toolhead and a shorter motor provides sufficient torque.
- Your driver cannot regulate current or lacks adequate cooling.
Contents
- 1 NEMA 17 17HS8401 stepper motor.
- 1 approximately one-metre four-conductor cable.
The bracket, pulley, coupling, driver, mounting screws and power supply are sold separately.