

- Stock: 22
- Model: 17HS4401s-09
Model:

17HS2408

17HS3401

17HS4401

17HS4401s-09

17HS8401

17hs8401S-09

17HS6401

17HS6401s-09
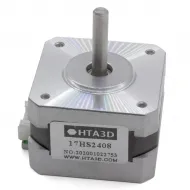
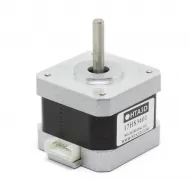
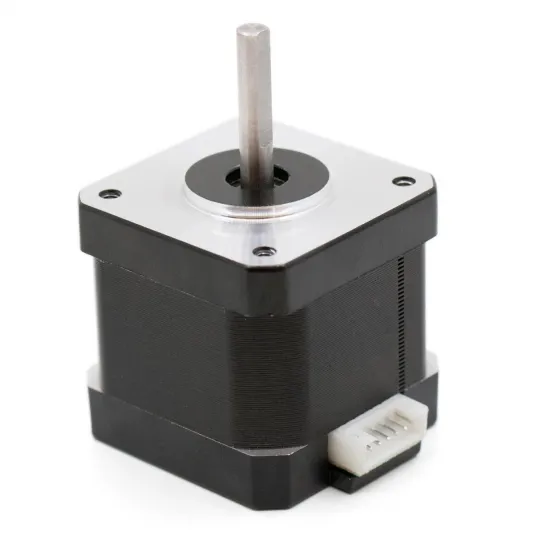
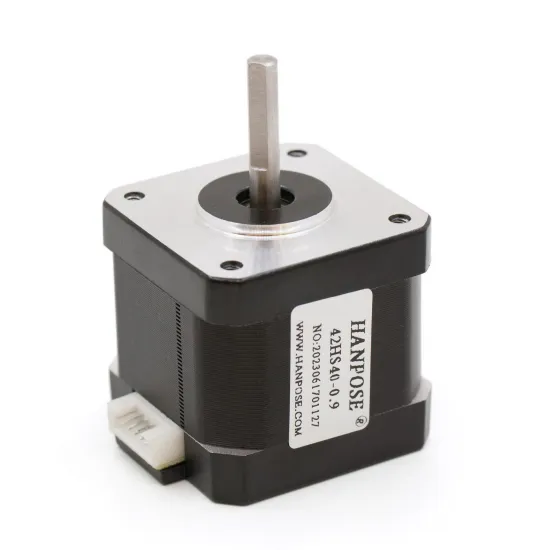
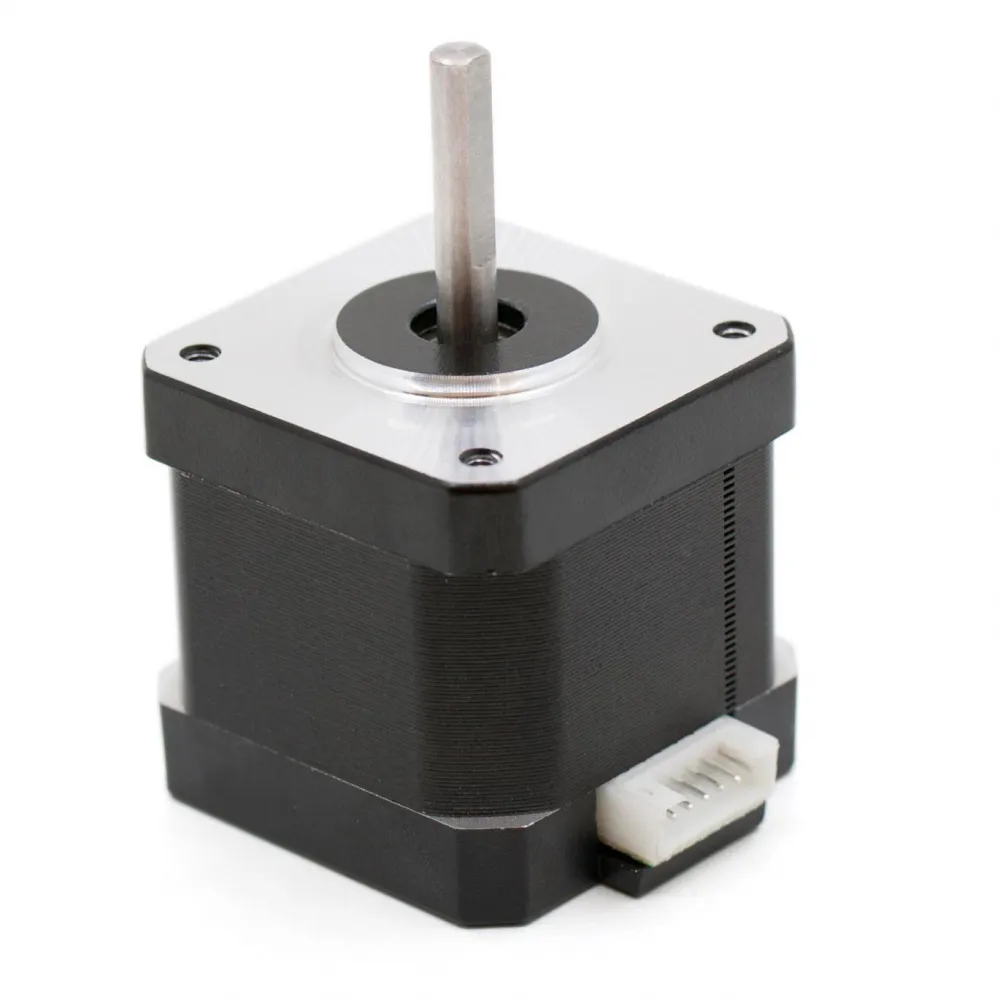
Bipolar hybrid 0.9° NEMA 17 stepper motor, reference 42HS40-0.9 / 17HS4401S-09, with a 40 mm body and a 5 mm front D shaft. Its 400 full steps per revolution provide greater nominal angular command resolution than a conventional 1.8° motor while retaining a compact format for 3D printers, CNC machines, plotters, lasers and automation projects.
This version has a declared minimum holding torque of 40 N·cm and weighs approximately 280 g. It is the most compact option in this family and may suit installations where space or moving mass matters, provided its dynamic torque is sufficient for the transmission and acceleration.
Nominal specifications
| Feature | Value |
|---|---|
| Format | NEMA 17, bipolar, 2 phases, 4 leads |
| Step angle | 0.9°; 400 full steps/rev |
| Rated current | 1.7 A/phase |
| Phase resistance / inductance | 1.5 Ω / 2.8 mH |
| Minimum holding torque | 40 N·cm (0.40 N·m) |
| Detent torque | 2.2 N·cm max. |
| Rotor inertia / weight | 54 g·cm² / 280 g |
Dimensions and mounting
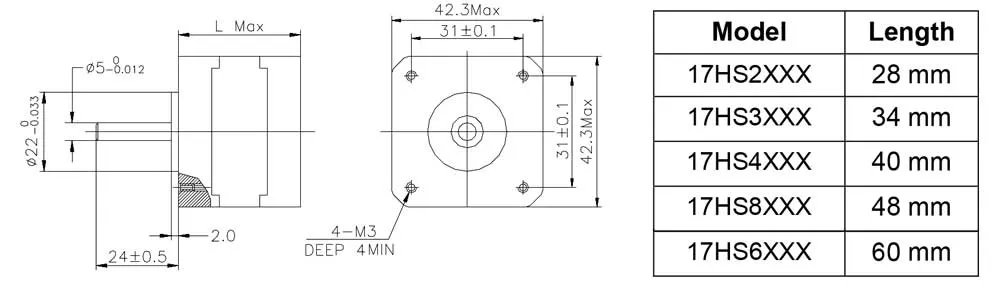
- Face: 42.3 mm maximum.
- Body length: 40 mm.
- Mounting pattern: 31 ±0.1 mm centres.
- Threads: 4 × M3, 4 mm minimum useful depth.
- Pilot: Ø22 × 2 mm.
- Front shaft: Ø5 × 24 ±0.5 mm, D profile.
- Approximately 1 m detachable cable included.
Driver, current and wiring
Use a current-regulated bipolar driver; never connect the motor directly to a 12 or 24 V supply. A4988, DRV8825 and TMC drivers may be suitable when the board, cooling and available current are appropriate. There is no universal VREF for potentiometer modules because it depends on the driver, sense resistor and module revision.
With a configurable TMC, 0.8-1.0 A RMS is a cautious starting range, to be increased only when required and after checking motor and driver temperatures. Identify coil pairs by continuity: one complete pair connects to A1/A2 and the other to B1/B2. Never assume the colour order or plug/unplug the motor while powered.
Marlin, Klipper and RepRapFirmware
A 0.9° motor has 400 full steps per rotation. When replacing a 1.8° motor without changing transmission or microsteps, steps/mm must be doubled.
- Marlin: set
DEFAULT_AXIS_STEPS_PER_UNITor useM92. At 16 microsteps: 160 steps/mm for GT2 20T and 800 steps/mm for TR8×8. - Klipper: use
full_steps_per_rotation: 400; without reduction,rotation_distance: 40for GT2 20T or8for TR8×8. - RepRapFirmware: use
M92for steps/mm andM906for current where the electronics support software control.
These are mathematical examples only. Pulley teeth, belt pitch, leadscrew lead, gearing and microsteps must match the actual machine.
Compatibility and selection
NEMA 17 primarily defines the front mounting interface; it does not guarantee matching current, torque, shaft, connector or pinout. Verify every item before replacing a motor in an Ender, Original Prusa, Voron, RatRig, HPRO or any other specific machine.
For more static torque, compare the 0.9° NEMA 17 42-48 and 0.9° NEMA 17 42-60. Extra length also adds mass and inertia, so it may not improve a fast axis.
It is for you if
- You need 400 full steps per revolution.
- You need a compact motor with a 5 mm D shaft.
- You can configure steps/mm, current, acceleration and wiring.
It is not for you if
- You need a drop-in replacement without checking electronics and pinout.
- Your application requires more torque than the 40 mm body can provide.
- You expect absolute accuracy: angular resolution does not remove backlash, flex or missed steps.
When dimensions match, it can be combined with the NEMA 17 L bracket, 20-tooth GT2 pulley for a 5 mm shaft and a configurable TMC2209 driver.
Contents: 1 motor and an approximately 1 m cable. Bracket, pulley, driver, power supply and screws are not included.