

- Stock: 137
- Model: GT2-20T-ID5-10mm
Model:

16T - belt 6mm

16Z - 9 and 10mm belt

16T POWGE- belt 6mm POWGE

16Z - belt 10mm POWGE

20T - belt 6mm

20T - 9 and 10mm belt

20Z - belt 6mm POWGE

20Z - belt 10mm POWGE

36T - belt 6mm

80T POWGE 6mm belt

80T - belt 6mm
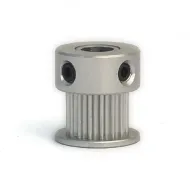
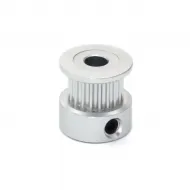
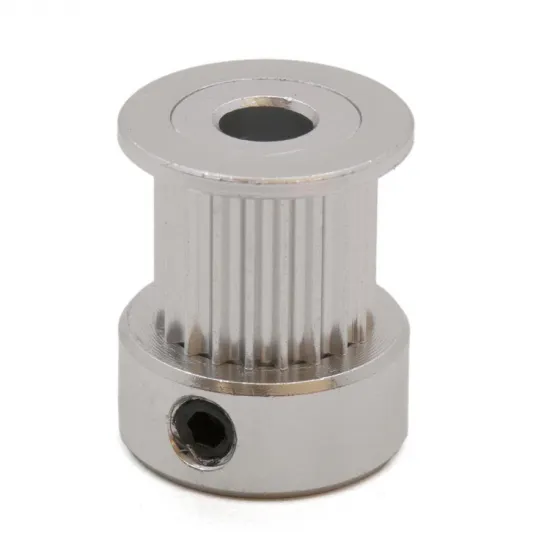
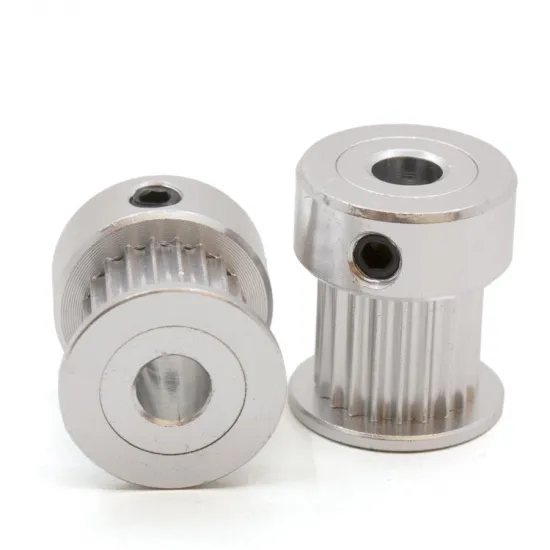
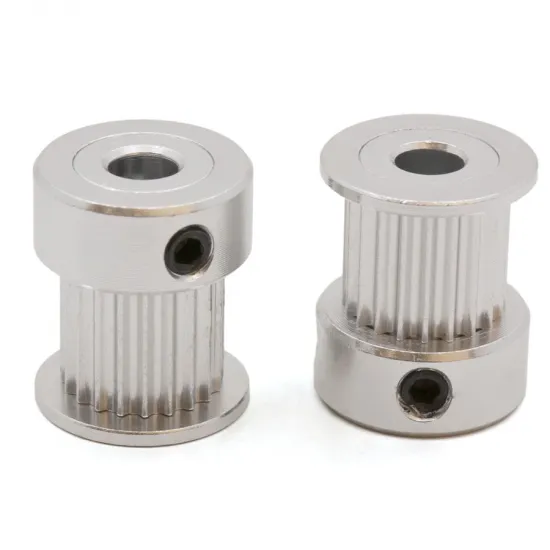
GT2 20-tooth drive pulley for 9 and 10 mm belts, made of aluminium and designed to be secured to a 5 mm shaft with two M2 grub screws.
The pulley is locked to the motor shaft and directly transfers movement to the belt. The 20-tooth format provides more linear travel per revolution and a larger belt bending radius than a 16-tooth pulley.
Features and dimensions
- Type: toothed drive pulley.
- Profile: GT2 / 2GT, 2 mm pitch.
- Number of teeth: 20.
- Compatible belt widths: 9 and 10 mm.
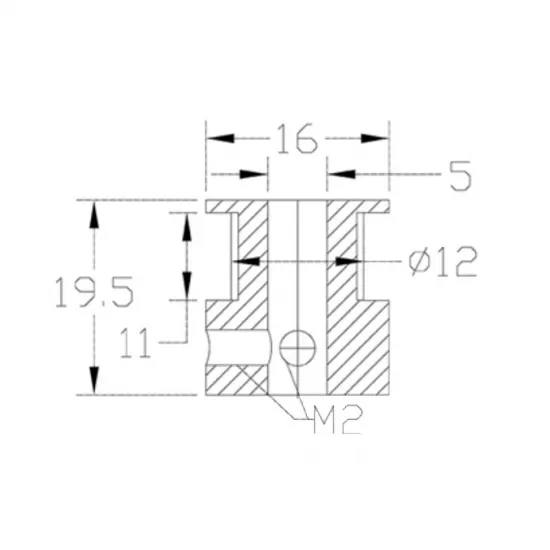
- Inner diameter: Ø5 mm.
- Approximate toothed section diameter: Ø12 mm.
- Flange diameter: approximately Ø16 mm.
- Usable width shown in the drawing: approximately 11 mm.
- Overall height: approximately 19.5 mm.
- Fastening: two radial M2 grub screws.
- Material: aluminium.
Motor-shaft installation
The Ø5 mm bore is dimensionally compatible with many NEMA 17 motors using a 5 mm shaft, but the exact motor documentation or a direct measurement should be checked.
Whenever possible, place one grub screw against the flat section of the shaft. Tighten both screws gradually and alternately to avoid shifting or tilting the pulley.
Before moving the machine, verify that the belt engages correctly, remains centred between the flanges and maintains alignment through a complete revolution.
Compatibility
It is compatible with 9 and 10 mm GT2 belts, including our wear-resistant 9 mm GT2 belt, 9 mm POWGE GT2 RF belt, wear-resistant 10 mm GT2 belt and 10 mm POWGE GT2 belt.
It can be used in 3D printers, CNC machines and custom CoreXY mechanisms specifying a 20T drive pulley, a 5 mm shaft and a 9 or 10 mm belt. Compatibility should not be assumed solely because the machine uses a NEMA 17 motor.
Common Voron configurations use 6 mm belts, so this wider version is not a direct replacement unless the system has been specifically modified.
For a more compact transmission, see the GT2 16T drive pulley for 9 and 10 mm belts. For a branded alternative, see the POWGE GT2 20T pulley for 10 mm belts, checking its bore diameter first.
Firmware configuration
With direct drive, the theoretical travel per revolution is:
20 teeth × 2 mm = 40 mm per revolution
With a 1.8° motor, 200 full steps per revolution and 16 microsteps, the theoretical setting is:
(200 × 16) ÷ 40 = 80 steps/mm
These values only apply when no reduction is used and the driver is actually configured for 16 microsteps.
- Marlin: configure the axis using
DEFAULT_AXIS_STEPS_PER_UNITorM92. Save withM500when EEPROM is enabled. - Klipper: for direct GT2 drive, use a theoretical
rotation_distance: 40. Keepmicrostepsand, where applicable,gear_ratiocorrectly configured. - RepRapFirmware: enter the calculated value with
M92inconfig.g.
In a CoreXY system, both motor transmissions must use the same tooth count and configuration. Do not combine a 16T pulley on one motor with a 20T pulley on the other.
Contents: 1 drive pulley with two grub screws.