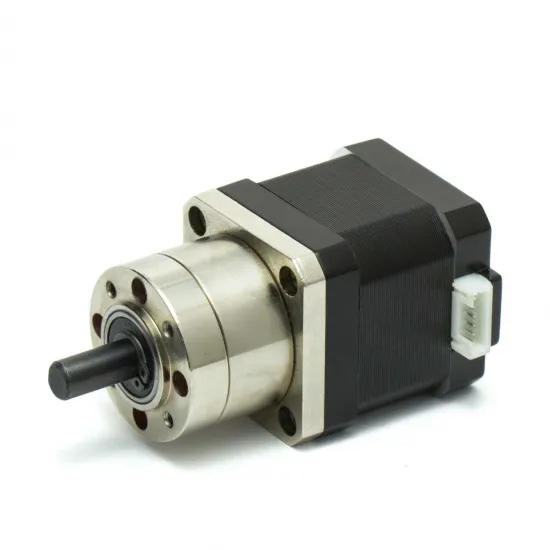


- Stock: 1
- Model: 17HS4401S-PG518
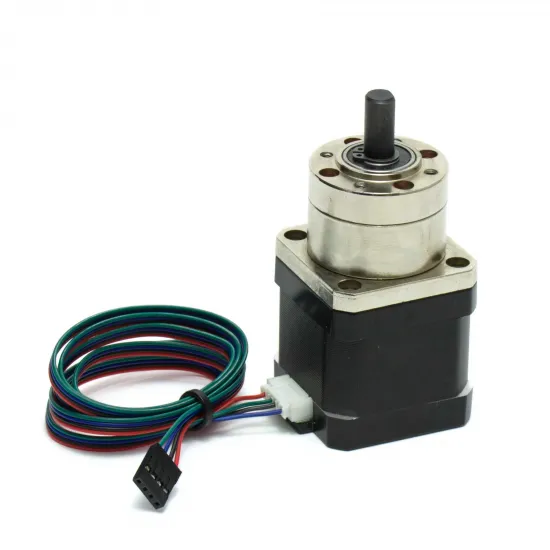
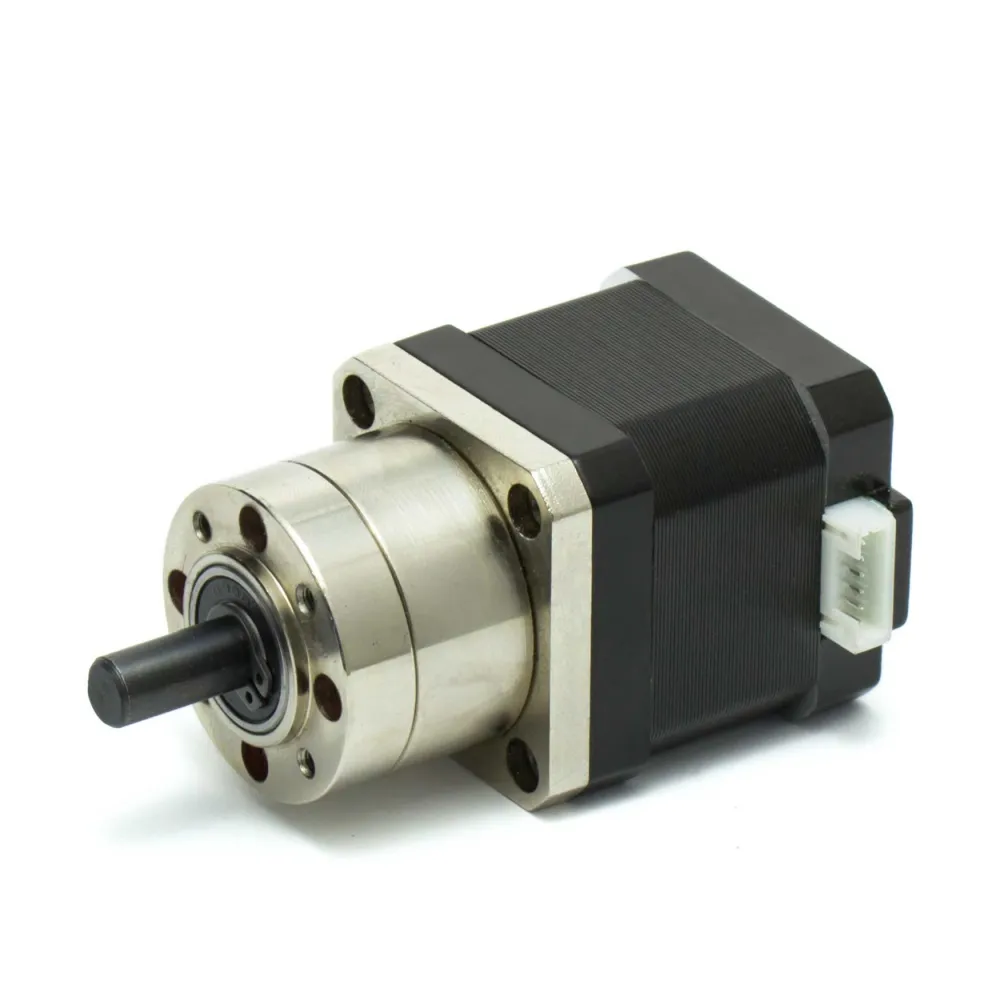
The 17HS4401S-PG518 combines a 1.8° bipolar NEMA 17 stepper motor with a single-stage planetary gearbox whose exact ratio is 57:11, or approximately 5.18:1. It is intended for mechanisms requiring more low-speed torque and resolution than a direct-drive NEMA 17.
The reduction converts the motor's 200 full steps per revolution into 1036.36 full steps per output-shaft revolution, with an effective angle of approximately 0.3474° per full step. Its 8mm output shaft accepts gears, couplings or transmission components designed for that diameter.
Electrical and gearbox specifications
| Parameter | Nominal value | Meaning |
|---|---|---|
| Motor type | Bipolar, 2 phases and 4 wires | Requires a current-regulated bipolar driver |
| Motor step angle | 1.8° | 200 full steps per revolution before the gearbox |
| Rated current | 1.68A per phase | Driver-setting reference limit, not fixed PSU draw |
| Phase resistance | 1.65Ω | Approximately 2.77V resistive equivalent at rated current |
| Phase inductance | 3.2mH ±20% at 1kHz | Affects current rise and available torque at speed |
| Gearbox type | Single-stage planetary | More compact and coaxial than many external reductions |
| Exact ratio | 57:11 = 5.1818:1 | The output turns once for every 5.1818 motor revolutions |
| Stated efficiency | Approx. 90% | Torque multiplication is neither ideal nor lossless |
| Nominal static output torque | Approx. 1.68N·m | Calculated static value at rated current; running torque falls as speed rises |
| Stated axial / radial load | 50N / 100N | Reference maximum values; design with a safety margin |
What the 5.18:1 reduction provides
The gearbox increases low-speed torque and output angular resolution. In exchange, it reduces maximum output speed by approximately the same factor and adds mass, mechanical losses and some gear play. It is therefore better suited to feeders, dosing systems, stationary Bowden extruders, indexers and slow mechanisms than to fast axes.
| Driver microsteps | Pulses per output revolution | Use |
|---|---|---|
| Full step | 1036.36 | Basic mechanical output resolution |
| 1/8 | 8290.91 | Lower pulse rate with smooth operation |
| 1/16 | 16581.82 | Common starting point |
| 1/32 | 33163.64 | Higher pulse demand without removing mechanical play |
The old 1036-step figure is an approximation. Use the exact 57:11 ratio for calculations and firmware. Microstepping mainly improves smoothness and noise; it does not proportionally multiply absolute accuracy or remove gearbox backlash.
Dimensions and mounting
| Dimension | Nominal value |
|---|---|
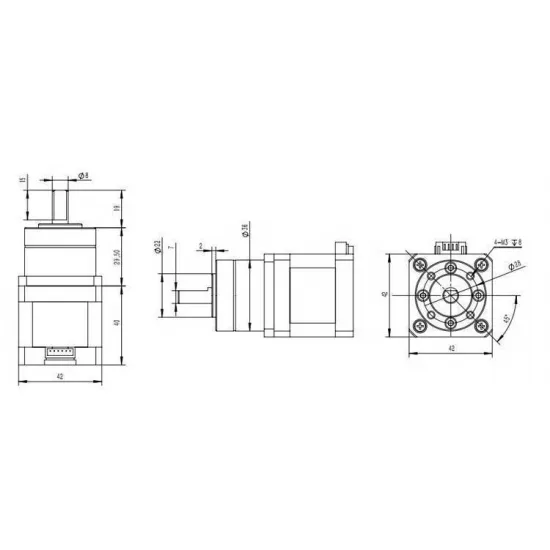
| Motor face | 42 × 42mm, NEMA 17 frame |
| Motor body length | 40mm |
| Gearbox | Approx. 36mm diameter × 29.5mm |
| Motor + gearbox length | Approx. 69.5mm, excluding shaft |
| Output shaft | 8mm diameter × 15mm |
| Gearbox front mounting | 4 × M3 threads, stated 8mm depth, nominal 28mm pitch circle |
| Approximate weight | 0.45kg |
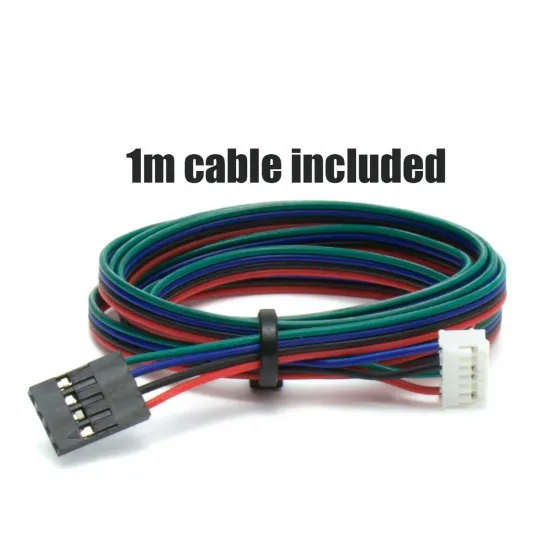
| Included cable | 4 wires, approximately 1m |
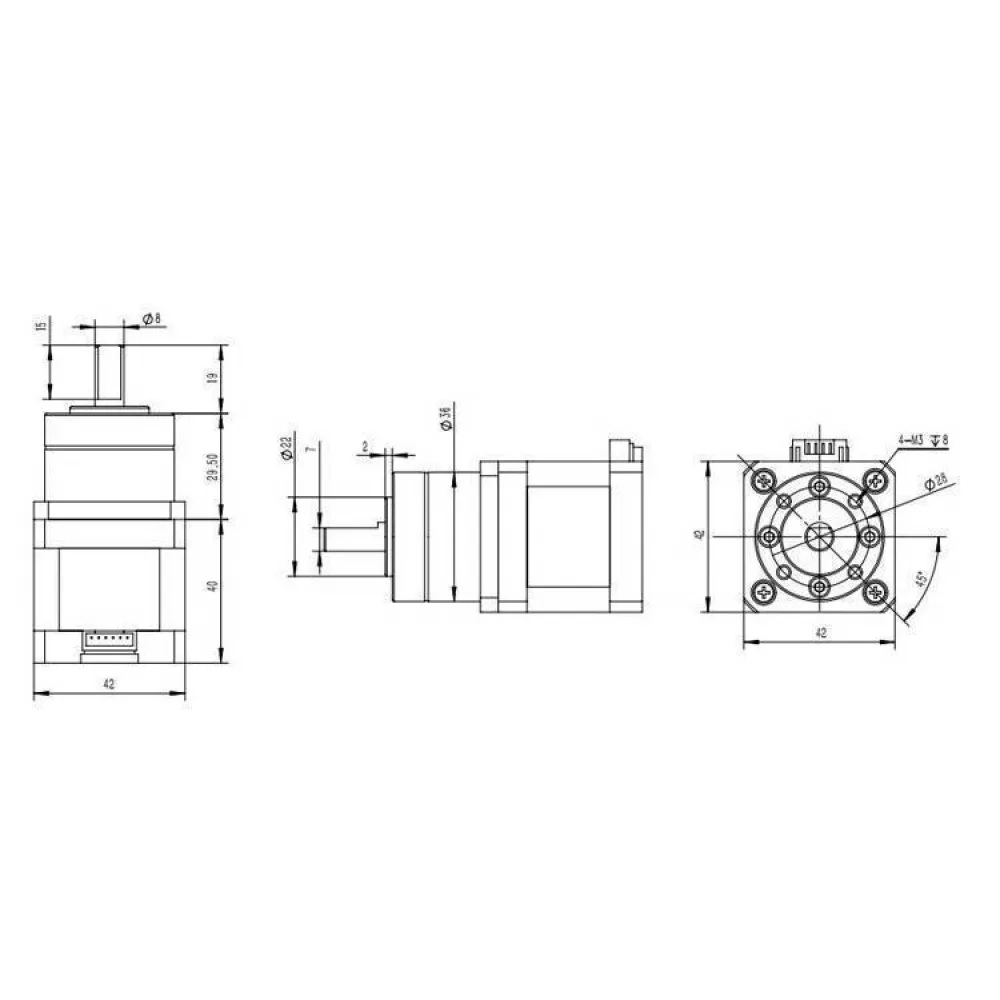
Check clearance for the complete assembly, cable exit and the component fitted to the shaft. Use M3 screws of a suitable length: exceeding the available thread depth may damage the gearbox or prevent the assembly from seating correctly.
Wiring and driver adjustment
The motor has two bipolar windings. Cable colours are not universal, although this motor family commonly pairs black-green and red-blue. Always verify the pairs with a multimeter: the two wires showing continuity belong to the same winding.
- Disconnect both PSU and USB before handling the cable.
- Find the two winding pairs by continuity or resistance.
- Connect one complete pair to A1/A2 and the other to B1/B2.
- If the motor vibrates without turning, switch off and check that wires from different windings have not been mixed.
- Reverse direction in firmware or, with power removed, swap both wires of one winding.
Never connect or disconnect the motor while the driver is powered. The resulting voltage transient can damage the controller.
It is electrically compatible with bipolar drivers supporting its current and required pulse rate. Potentiometer-adjusted modules have no universal VREF: the formula depends on sense resistance and module revision. The BIGTREETECH TMC2209 driver provides UART current control when correctly configured and cooled.
For TMC drivers using RMS current, a cautious starting range is usually 0.8-1.0A RMS. Increase only if torque is insufficient and motor and driver temperatures remain safe. Do not blindly copy the 1.68A phase rating into an RMS field.
Bowden extruder example with an MK7 drive gear
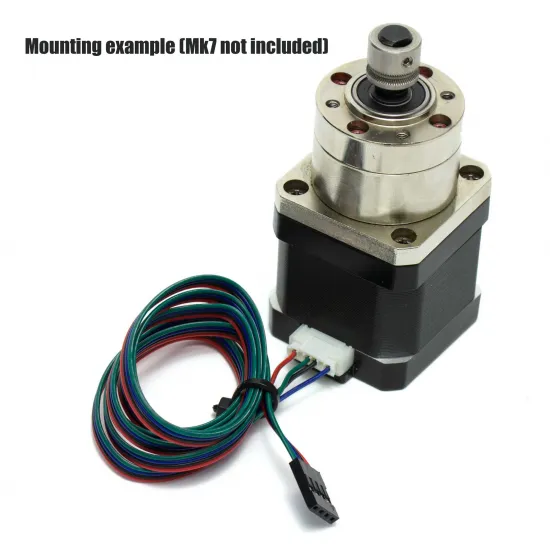
The 8mm shaft accepts the 8mm-bore stainless-steel MK7 drive gear. With its approximate 10.8mm effective diameter, the combination gives an initial theoretical value of 488.72 steps/mm at 16 microsteps.
This solution prioritises force and low-speed control. At around 0.45kg and with a 5.18:1 reduction, it is more naturally mounted on a fixed Bowden extruder than on a moving direct-drive toolhead. A Bowden setup must also be checked to ensure output speed and controller pulse rate can support the required retractions.
Marlin
With the above MK7 gear and 16 microsteps, start with:
M92 E488.72Command a measured extrusion at operating temperature. If 100mm is requested and 95mm actually moves, the new value is 488.72 × 100 ÷ 95. With EEPROM enabled, save the validated result using M500.
With a configurable TMC, a cautious starting point can be E0_CURRENT 900 in configuration or M906 E900 for a temporary test, provided that the Marlin version and driver use RMS milliamps.
Klipper
Klipper can declare the exact ratio separately. For the 8mm-bore MK7 gear with an approximate 10.8mm effective diameter:
[extruder]
microsteps: 16
full_steps_per_rotation: 200
gear_ratio: 57:11
rotation_distance: 33.929
Here, rotation_distance is the feed from one full revolution of the final drive gear. Do not divide 33.929 by 5.1818 again: the reduction is already declared in gear_ratio. Calibrate rotation distance afterwards with a measured extrusion.
For a TMC2209, run_current: 0.90 is a cautious starting point to be tuned for torque, temperature and cooling.
RepRapFirmware
A natural initial config.g setup for the same assembly is:
M350 E16 I1
M92 E488.72
M906 E1200 I30
RepRapFirmware expresses M906 in peak milliamps; 1200mA is a cautious starting point, not a final setting. With an external driver, M350 or M906 may not physically control microsteps or current, which must then be set on the driver itself.
Compatibility and replacement use
It can be integrated into a 3D printer, light CNC machine, robot or automation system when the design explicitly accepts:
- An approximately 69.5mm assembly plus shaft and coupling.
- A compatible 8 × 15mm output shaft and mounting interface.
- Slow 5.18:1 geared motion with some mechanical play.
- A current-regulated bipolar driver with sufficient pulse rate.
- Radial load, axial load, acceleration and running torque within safe margins.
It is not a direct replacement for Ender-3, CR-10, Original Prusa or Voron motors merely because those machines use NEMA 17 frames. They normally use direct 5mm shafts, different lengths and different dynamics. When reduction is unnecessary and speed is more important, the direct-drive 5mm-shaft NEMA 17 17HS4401 is often a more natural choice.
It is for you if
- You need high low-speed torque and resolution in a compact coaxial assembly.
- Your mechanism accepts an 8mm shaft, the assembly length and gearbox mounting interface.
- The motor remains fixed or its mass does not harm system dynamics.
- You can calibrate steps, current, speed and acceleration on the actual machine.
It is not for you if
- You need a fast direct NEMA 17 for a 5mm-bore pulley or coupling.
- You require backlash-free reversing position or absolute accuracy based only on microstepping.
- You want to install it on a lightweight moving direct-drive toolhead.
- Your electronics lack a current-regulated driver or cannot provide the required pulse rate.
Package contents
- 1 × NEMA 17 stepper motor with 5.18:1 planetary gearbox.
- 1 × approximately 1m four-wire cable.
MK7 drive gear, driver, bracket, coupling, screws and power supply are sold separately.