

- Stock: 4
- Model: TMC5160Tplus-BTT

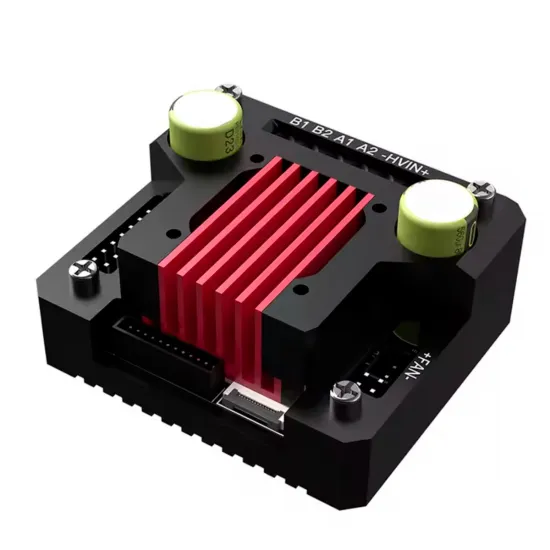
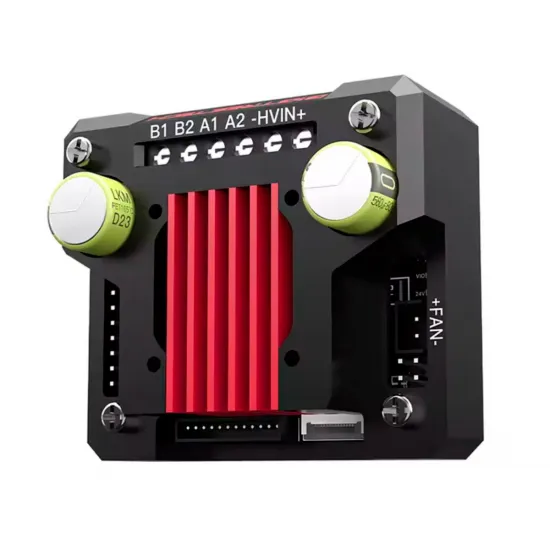
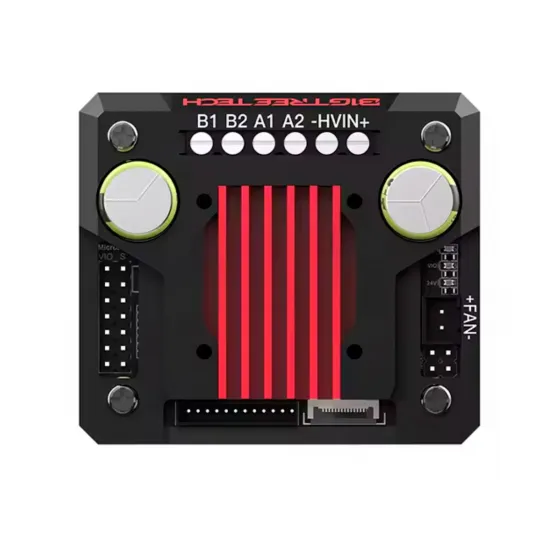
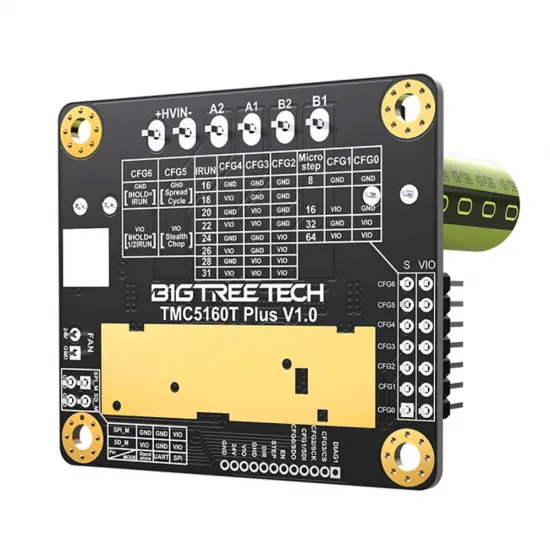
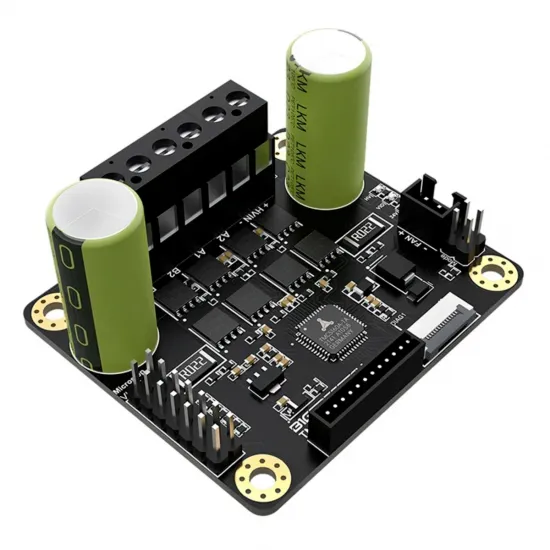
The BIGTREETECH TMC5160T Plus V1.0 is an external high-power driver for two-phase bipolar stepper motors. It combines a TMC5160-TA controller with eight external MOSFETs, a dedicated power terminal, heatsink enclosure and SPI connectivity, providing substantially more headroom than a conventional plug-in driver when the machine, power supply, motor and cooling are correctly sized.
This item is the enclosed V1.0 revision. It uses STEP/DIR for motion and SPI for configuration and diagnostics in Marlin or Klipper. Standard TMC and BIGTREETECH EZ socket adapters are included, but compatibility must be checked by pinout and power architecture; connector shape alone is not sufficient.
Main features
- Controller: TMC5160-TA with eight external MOSFETs.
- HVIN motor supply: 8-60 V DC according to BIGTREETECH's manual and technical artwork.
- Published maximum current: 10.6 A RMS and 15 A sine-wave peak; these are not universal settings.
- Sense resistors: 0.022 Ω.
- Control: STEP/DIR motion with SPI configuration and diagnostics.
- Modes: StealthChop2, SpreadCycle, StallGuard2, CoolStep and DcStep.
- Resolution: 1 to 256 microsteps.
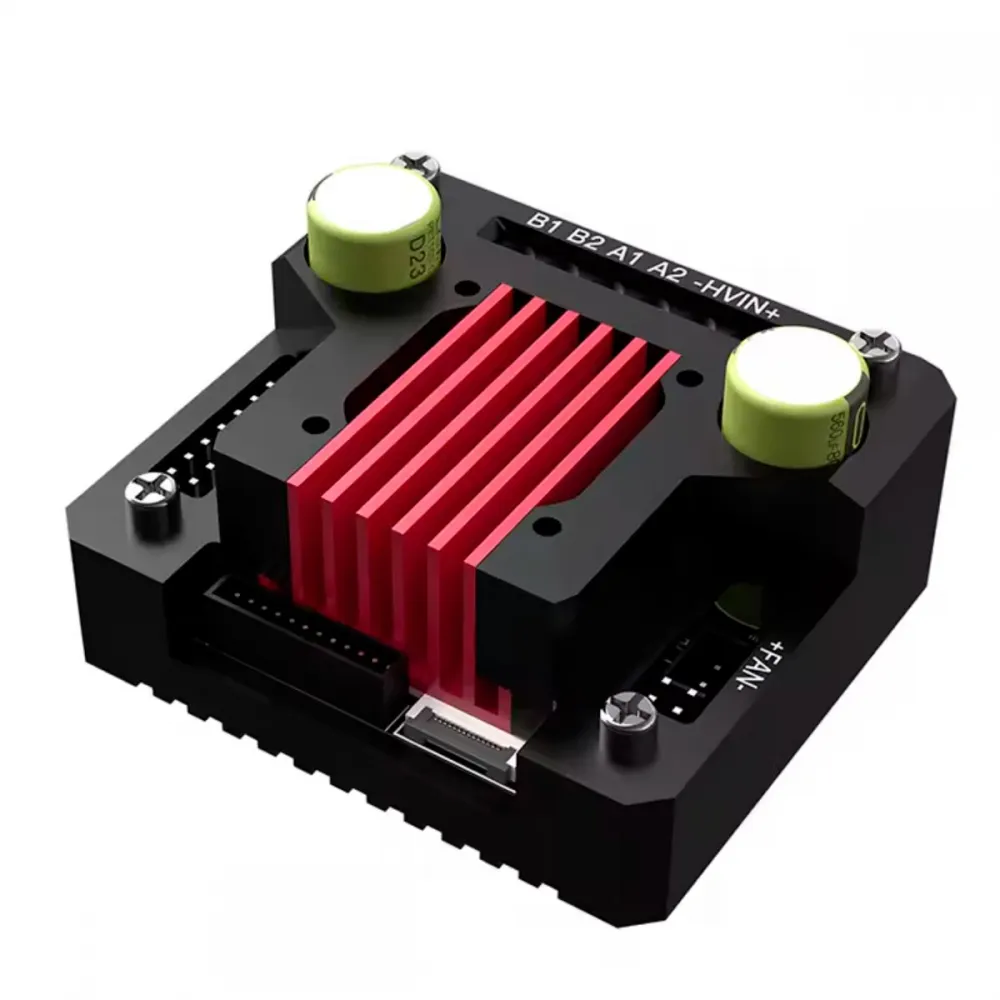
- Cooling: factory heatsink enclosure and connection for a 24 V 3010 fan.
- Included adapters: TMC Driver Adapter and EZ Driver Adapter.
- Reserved encoder interface for projects that explicitly implement it.
Technical specifications
| Parameter | Value |
|---|---|
| Model | BIGTREETECH TMC5160T Plus V1.0 |
| Motor | Two-phase bipolar stepper motor |
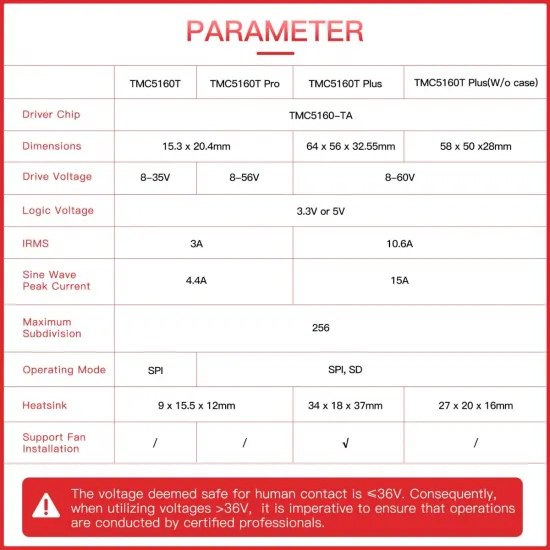
| HVIN motor supply | 8-60 V DC |
| VIO logic | 3.3 V or 5 V |
| Auxiliary board/adapter input | 24 V maximum |
| Published maximum current | 10.6 A RMS / 15 A sine-wave peak |
| Sense resistance | 0.022 Ω |
| Configuration interface | SPI |
| Motion signals | STEP/DIR |
| Microsteps | 1-256 |
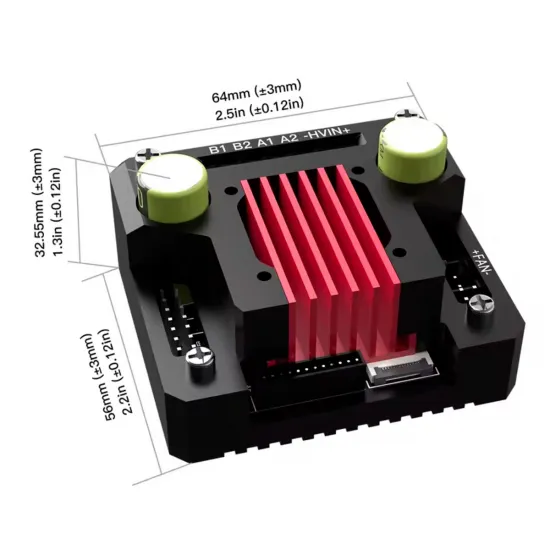
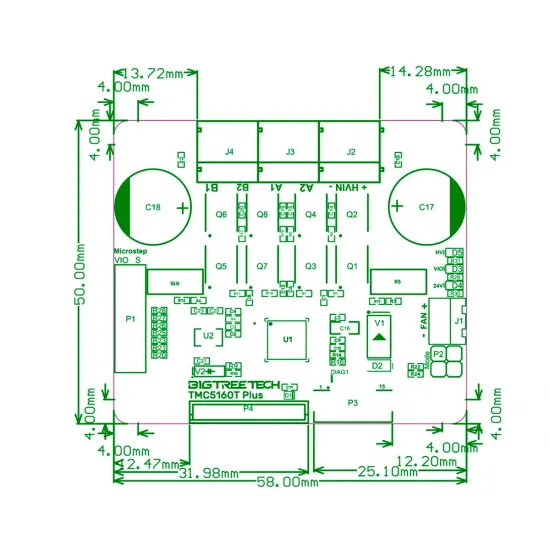
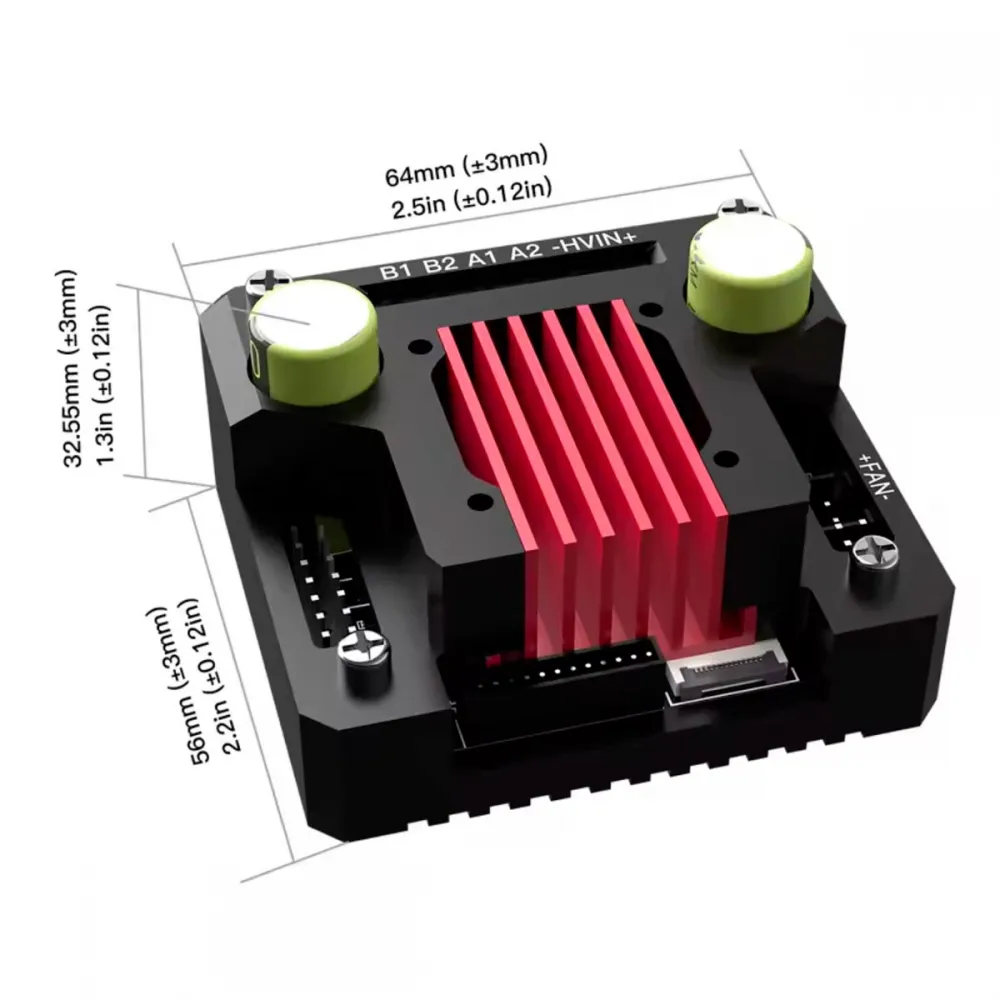
| Enclosed dimensions | 64 × 56 × 32.55 mm nominal |
| Bare-module dimensions | 58 × 50 × 28 mm nominal |
| Fan | 24 V 3010; always-on output |
Maximum current is not recommended current: 10.6 A RMS and 15 A peak are limits published by BIGTREETECH for the module. The real setting must start from the motor's allowed RMS current and be reduced when required by temperature, power supply, wiring, terminals, enclosure or duty cycle. BIGTREETECH requires active cooling above 3 A.
Three power domains that must not be confused
| Domain | Function | Limit |
|---|---|---|
| HVIN | External motor power through the screw terminal | Published 8-60 V DC |
| 24V | Auxiliary supply from the board/adapter and fan output | 24 V maximum |
| VIO | Control-signal logic level | 3.3 V or 5 V |
High-voltage motor power enters only through +HVIN and -HVIN. The cable from the controller board must never receive more than 24 V. Never route HVIN into a driver socket or assume that the whole controller board supports the voltage used by this module.
Controller-board and motor compatibility
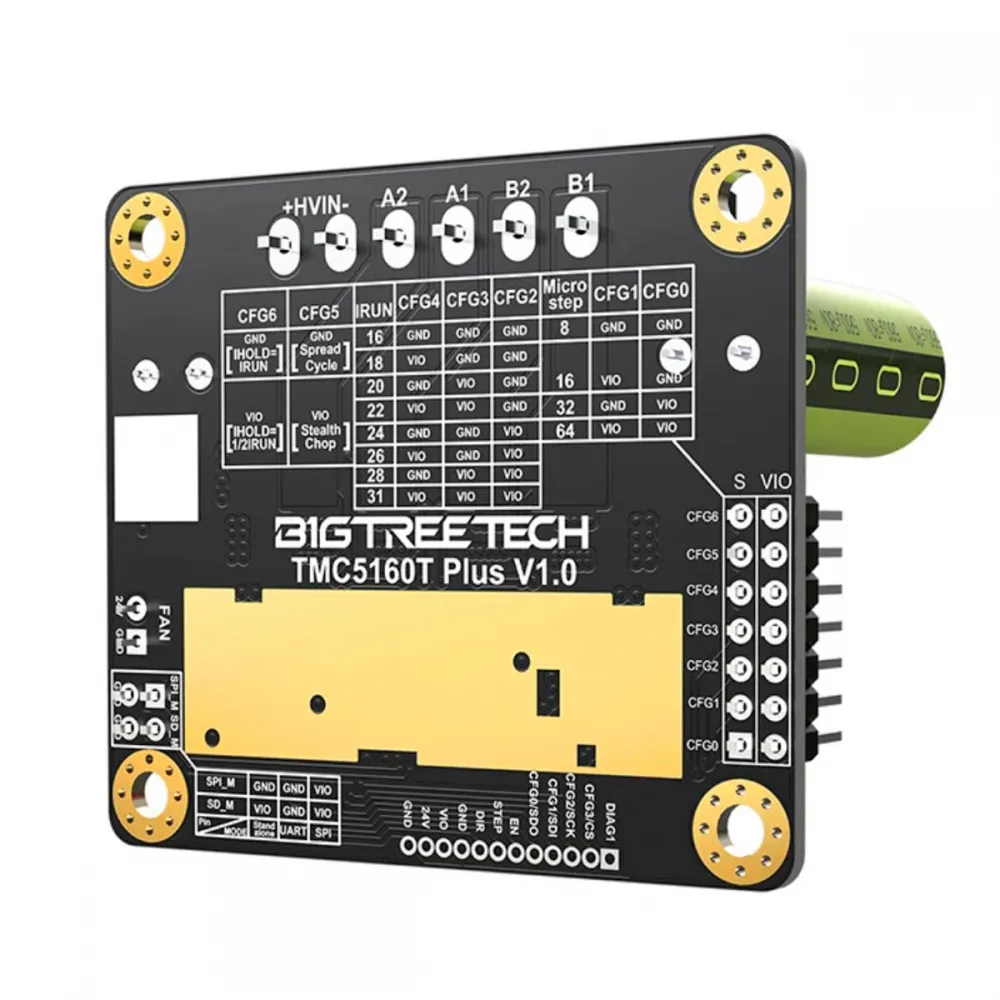
BIGTREETECH shows the SKR 3 with the standard TMC adapter and the Octopus MAX EZ with the EZ adapter. These are integration examples, not permission to copy their wiring to a different board. Every installation must match:
- Mechanical: room for the module, terminal, cable bend radius and airflow.
- Electrical: compatible VIO, auxiliary power at or below 24 V and correctly shared ground.
- Signals: STEP, DIR, EN, CS, SCK, MOSI and MISO mapped to the actual board pins.
- Firmware: TMC5160 SPI support and configuration for the exact board revision.
- Motor: two-phase bipolar type, identified coils and suitable RMS current.
- Power: supply, protection, wiring and terminals sized for the real voltage and current.
BIGTREETECH mentions 36, 42, 57 and 86 motor frame sizes in its testing, but external size does not guarantee compatibility. Motors of the same size can have very different current, inductance and thermal requirements.
StealthChop2, SpreadCycle and sensorless homing
StealthChop2 prioritises quiet operation at moderate speeds. SpreadCycle is usually more consistent as load, speed or acceleration increase. CoolStep can reduce current according to load, while StallGuard2 estimates motor load and can provide sensorless homing after correct wiring and calibration.
Sensorless homing is not automatic. A DIAG output must be wired to a compatible input and each axis calibrated on the real mechanism. A generic sensitivity value should not be copied to Z where a missed detection could drive the nozzle into the bed.
Safe installation
- Disconnect the main power supply and USB.
- Check the pinout of the selected controller board and adapter.
- Set selectors and jumpers for SPI while power is removed.
- Connect the motor coils to A1/A2 and B1/B2 without mixing the pairs.
- Connect motor power to +HVIN/-HVIN with correct polarity.
- Keep power from the controller board/adapter at 24 V or below.
- Install active cooling above 3 A and provide airflow at lower current when used in a closed enclosure.
- Configure SPI, 0.022 Ω and a conservative current before commanding motion.
- When powering up, follow BIGTREETECH's sequence: HVIN motor power first, controller/logic second.
- Verify communication and make short, low-speed moves before increasing performance.
Advanced electrical work: 60 V is the published upper limit, not a target operating voltage. Leave headroom for tolerances, regenerative peaks and transients. Above 36 V, BIGTREETECH restricts handling to qualified personnel. Do not remove the factory heatsink or connect/disconnect the motor while powered.
Basic Klipper configuration
Klipper provides a dedicated [tmc5160] section. Pins depend on the controller board, socket and revision and must be taken from its official configuration:
[tmc5160 stepper_x]
cs_pin: ACTUAL_CS_PIN
spi_bus: ACTUAL_SPI_BUS
run_current: RMS_CURRENT_VALIDATED_FOR_THE_MOTOR
sense_resistor: 0.022
stealthchop_threshold: 0
sense_resistor: 0.022 is particularly important: Klipper's default TMC5160 value is 0.075 Ω and does not match this module. If the board requires software SPI, replace spi_bus with spi_software_sclk_pin, spi_software_mosi_pin and spi_software_miso_pin using the actual pins.
run_current is RMS amperage and must suit the motor rather than the driver's maximum. Klipper discourages adding hold_current unless there is a specific need. After restarting, use DUMP_TMC STEPPER=stepper_x and do not move the axis until communication is correct.
Sensorless homing may use one diag0_pin or diag1_pin after checking the board schematic, followed by machine-specific driver_SGT calibration. There is no universal value.
Basic Marlin configuration
BIGTREETECH documents Marlin 2.0 or later over SPI. In Configuration.h, select the driver type for the relevant axis:
#define X_DRIVER_TYPE TMC5160In Configuration_adv.h, set RMS current, microsteps, CS and SPI bus for the board. Set the axis sense resistance to 0.022 Ω. If software SPI is required, enable TMC_USE_SW_SPI and define SCK, MISO and MOSI only from that board revision's pinout.
Compile for the exact board model and MCU. After flashing, use M122 to verify communication before commanding motion. Current must come from the motor specification and thermal testing, not from the module's published 10.6 A limit.
Which driver should you choose?
The TMC5160T Plus is intended for applications that genuinely need an external power stage, independent terminal and dedicated power installation. For a compact plug-in solution up to 3 A, the BIGTREETECH TMC5160 Pro V1.1 may be simpler. For systems up to 36 V that prioritise modern diagnostics and a compact format, consider the BIGTREETECH TMC2240.
It is for you if
- Your motor and application need more current than a compact driver can provide.
- You can provide a correctly sized external supply, protection, wiring and cooling.
- Your board supports SPI and you have verified every adapter pin.
- You need TMC5160 diagnostics, current control and a choice of StealthChop2 or SpreadCycle.
- You will validate temperatures and operation under real load.
It is not for you if
- You want a direct StepStick replacement without extra wiring or power supply.
- You only know the motor's NEMA size, not its current or coil wiring.
- You cannot provide active cooling when required.
- You intend to work close to 60 V without headroom, protection or power-electronics experience.
- Your board does not document compatible SPI, VIO, auxiliary power and pinout.
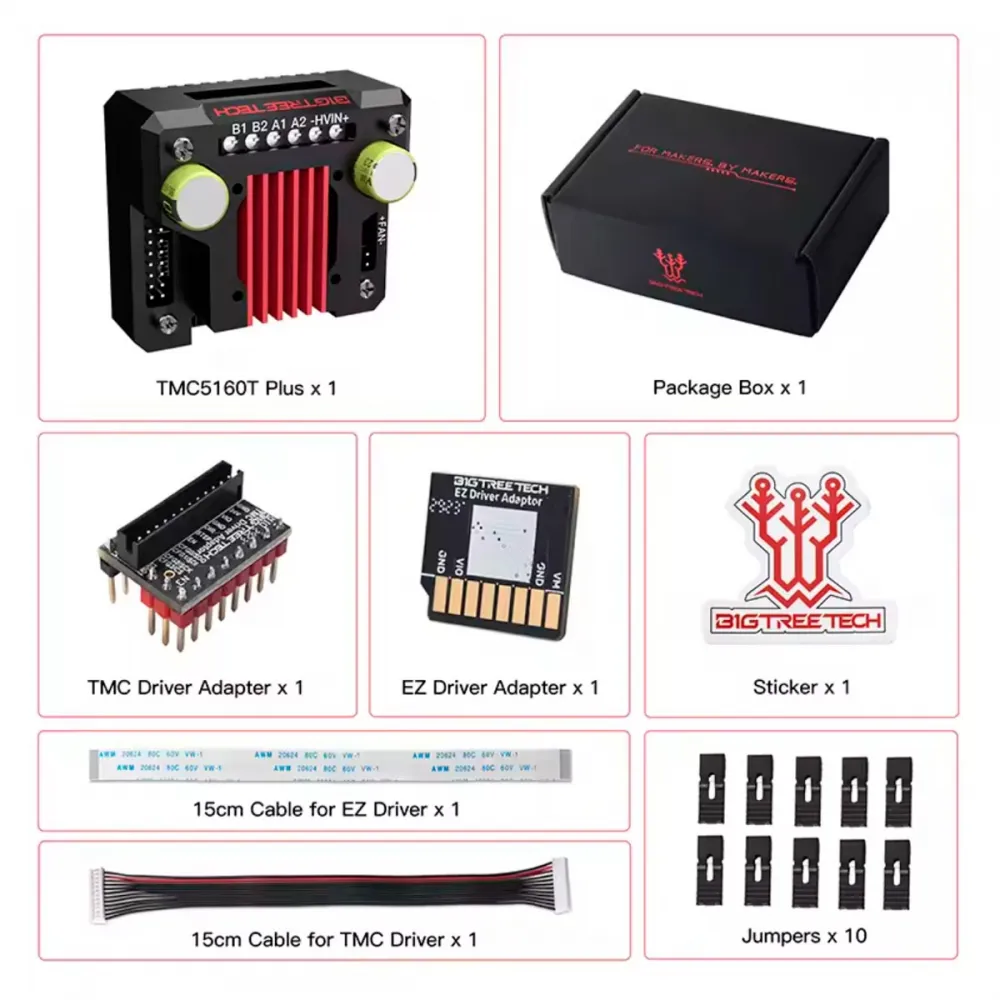
Kit contents
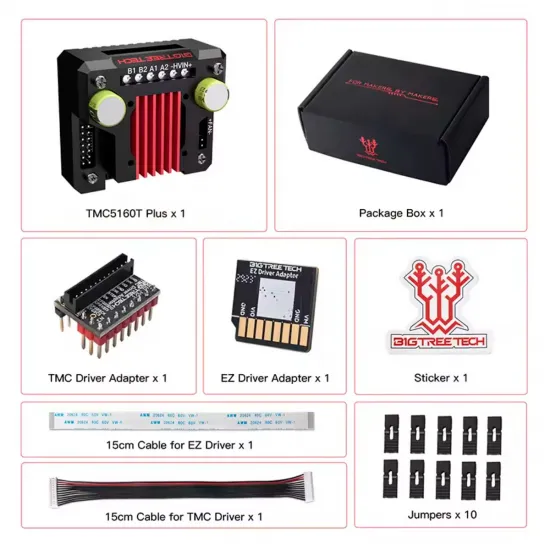
- 1 × enclosed BIGTREETECH TMC5160T Plus V1.0.
- 1 × TMC Driver Adapter.
- 1 × EZ Driver Adapter.
- 1 × 15 cm TMC cable.
- 1 × 15 cm EZ cable.
- 10 × jumpers.
- 1 × sticker.
The 3010 fan and its screws are sold separately. For active cooling, a 24 V 3010 axial fan can be used after checking the required mount and fasteners.
Manuals, schematics and future revisions are available in the official BIGTREETECH repository and Klipper's TMC5160 configuration reference.