

- Stock: 32
- Model: POWGE-GT2-20Z-6mm

Model:

16T - belt 6mm

16Z - 9 and 10mm belt

16T POWGE- belt 6mm POWGE

16Z - belt 10mm POWGE

20T - belt 6mm

20T - 9 and 10mm belt

20Z - belt 6mm POWGE

20Z - belt 10mm POWGE

36T - belt 6mm

80T POWGE 6mm belt

80T - belt 6mm
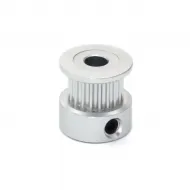
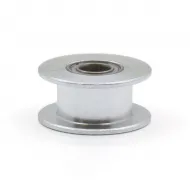
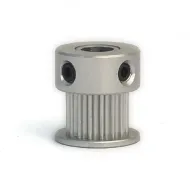
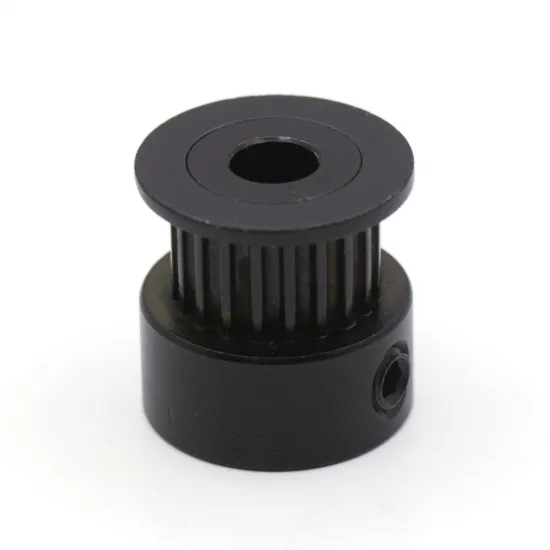
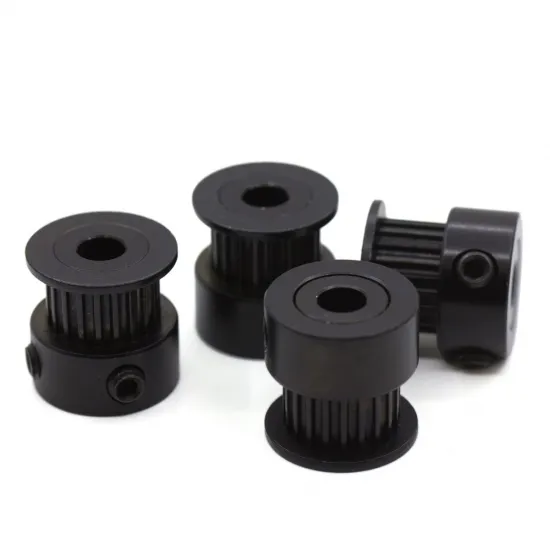
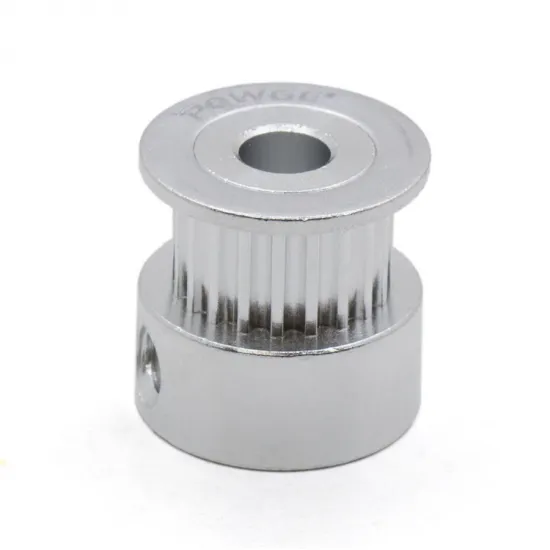
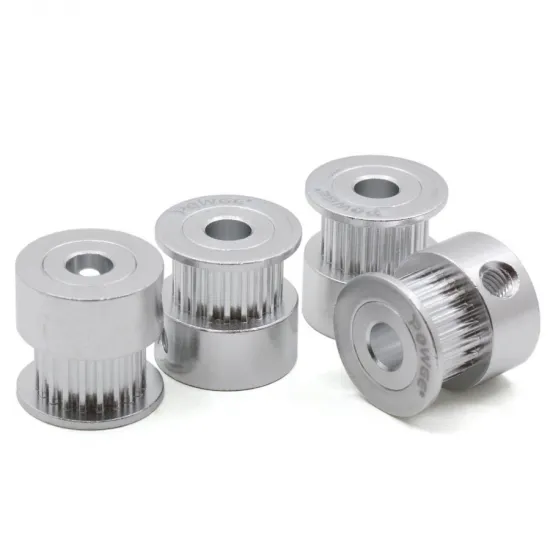
POWGE GT2 20-tooth drive pulley for 6 mm belts, made of 6061 aluminium and designed to be secured to a 5 mm shaft with two M4 grub screws.
Its 20T format provides a theoretical travel of 40 mm for each complete motor revolution when used with a 2 mm-pitch GT2 belt.
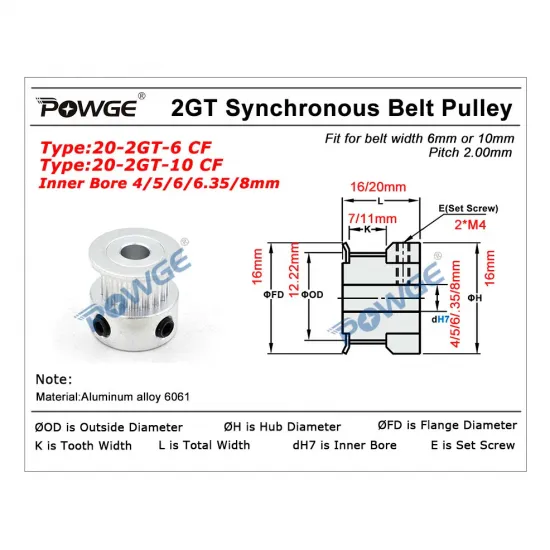
Features and dimensions
- Brand: POWGE.
- Type: toothed drive pulley.
- Profile: GT2 / 2GT, 2 mm pitch.
- Number of teeth: 20.
- Compatible belt width: 6 mm.
- Inner diameter: Ø5 mm.
- Toothed section outer diameter: Ø12.22 mm.
- Flange diameter: Ø16 mm.
- Hub diameter: Ø16 mm.
- Toothed width: 7 mm.
- Overall length: 16 mm.
- Fastening: 2 M4 grub screws.
- Material: 6061 aluminium alloy.
Installation
The Ø5 mm bore is dimensionally compatible with many NEMA 17 motors equipped with a 5 mm shaft. Whenever possible, position one grub screw against the flat section of the shaft and tighten both screws progressively.
Check that the pulley is aligned with the idlers and that the belt engages without continuously rubbing against the flange.
Compatibility
It is compatible with 6 mm GT2 belts, including the fibreglass-reinforced POWGE GT2 belt and low-vibration POWGE GT2 RF belt.
The combination of 20 teeth, a 5 mm shaft and a 6 mm belt dimensionally matches many CoreXY mechanisms and some Voron configurations. Check the bill of materials for the exact version and any specified brand or quality before treating it as a direct replacement.
In a CoreXY system, both drive pulleys must use the same tooth count. Do not combine a 20T pulley on one motor with a 16T pulley on the other.
For greater linear resolution or a more compact belt path, see the POWGE 16T drive pulley for 6 mm belts.
Firmware configuration
With direct drive:
20 teeth × 2 mm = 40 mm per revolution
With a 1.8° motor, 200 full steps per revolution and 16 microsteps, the theoretical setting is 80 steps/mm.
- Marlin: use
DEFAULT_AXIS_STEPS_PER_UNITorM92. - Klipper: use a theoretical
rotation_distance: 40. - RepRapFirmware: configure steps per millimetre with
M92inconfig.g.
Recalculate these values when gear reduction is present, different microstepping is used or the motor is not a 1.8° model.
Contents: 1 POWGE drive pulley with two grub screws.