

- Stock: 3
- Model: KrakenV1.1

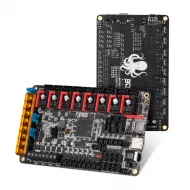
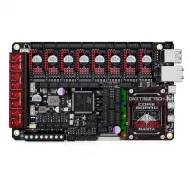
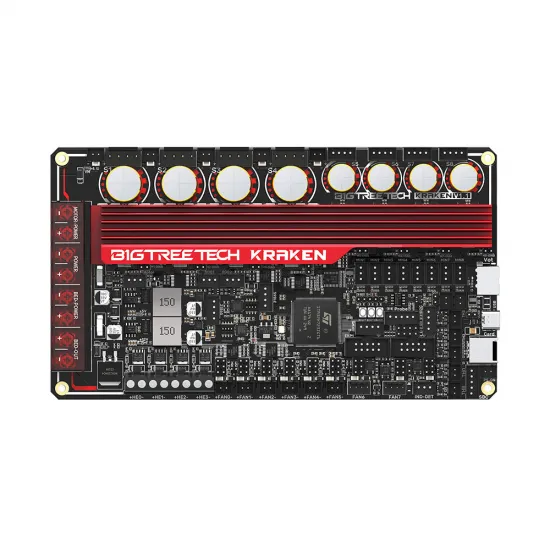
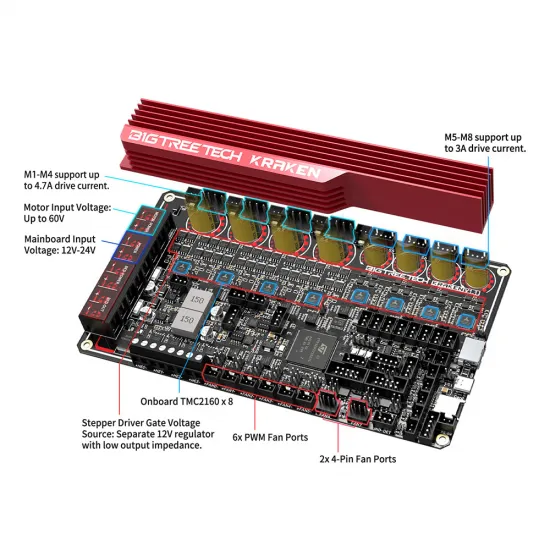
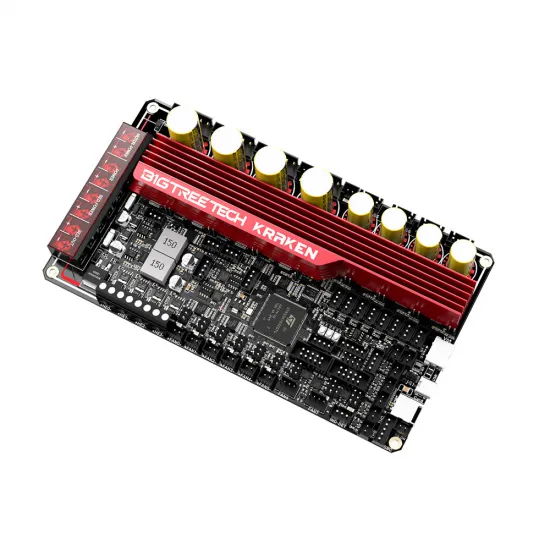
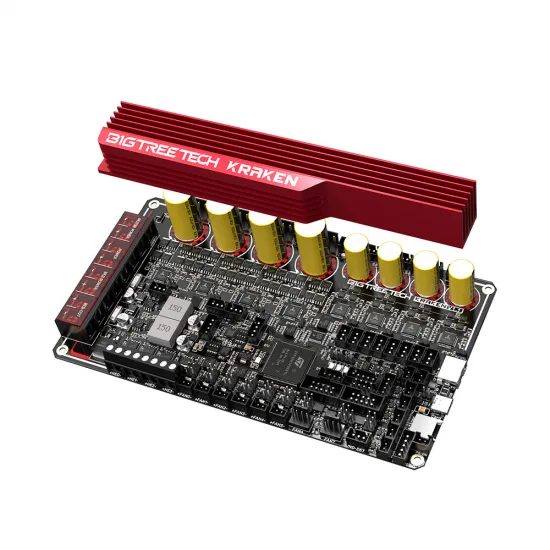
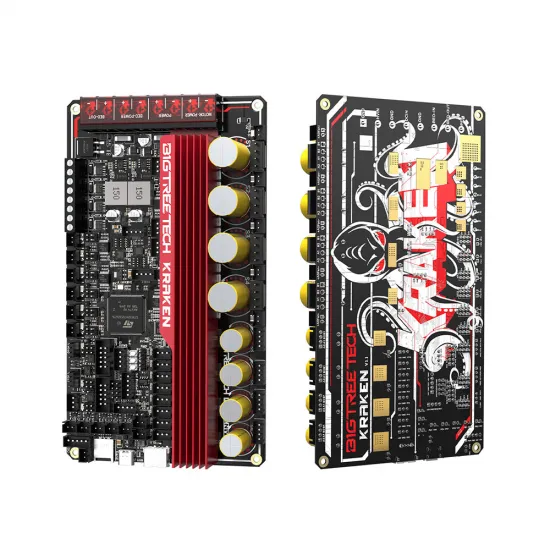
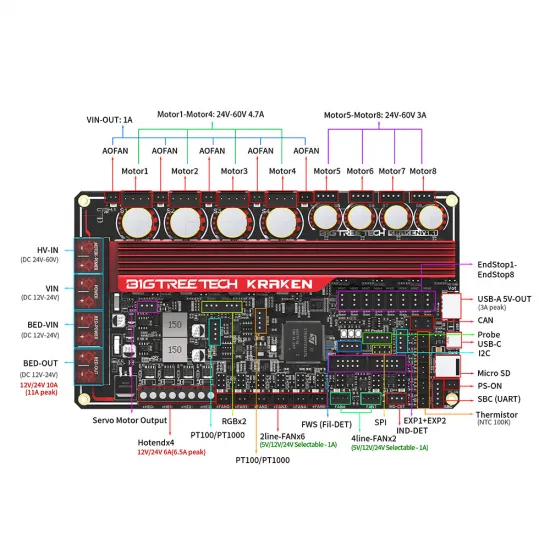
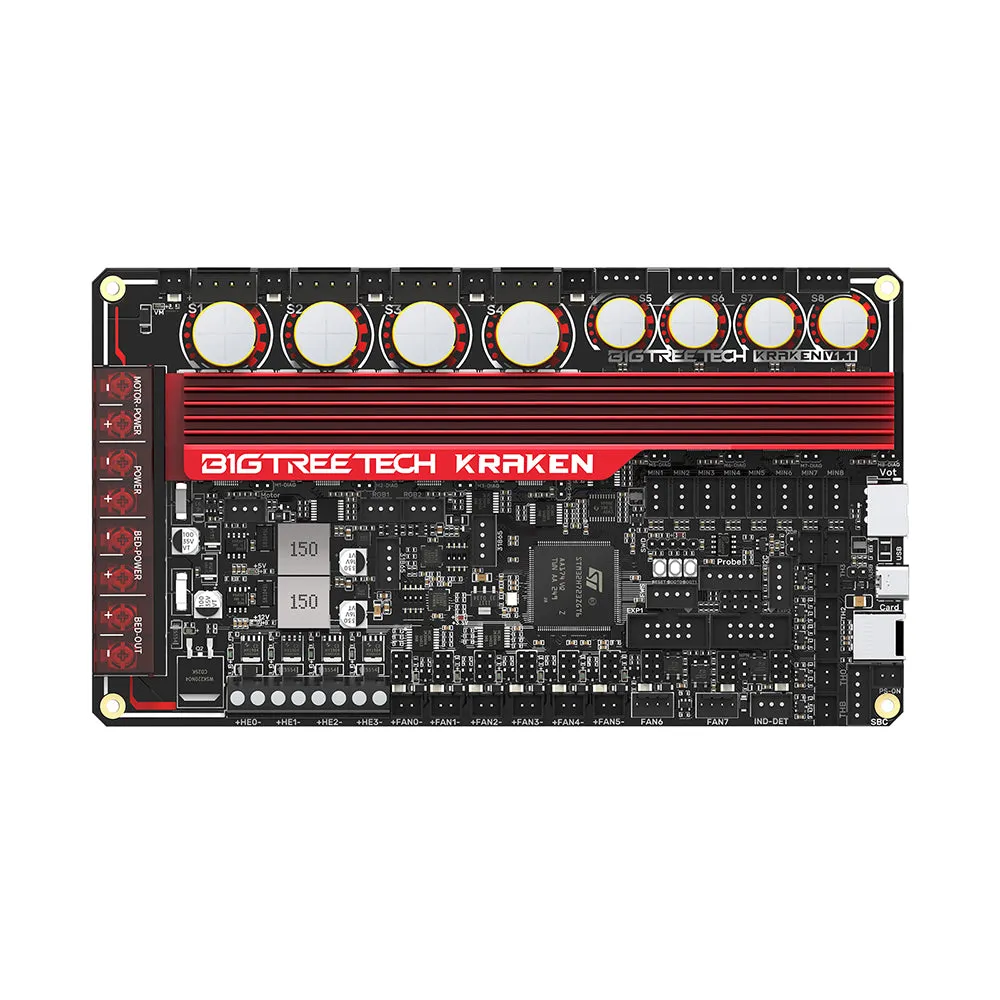
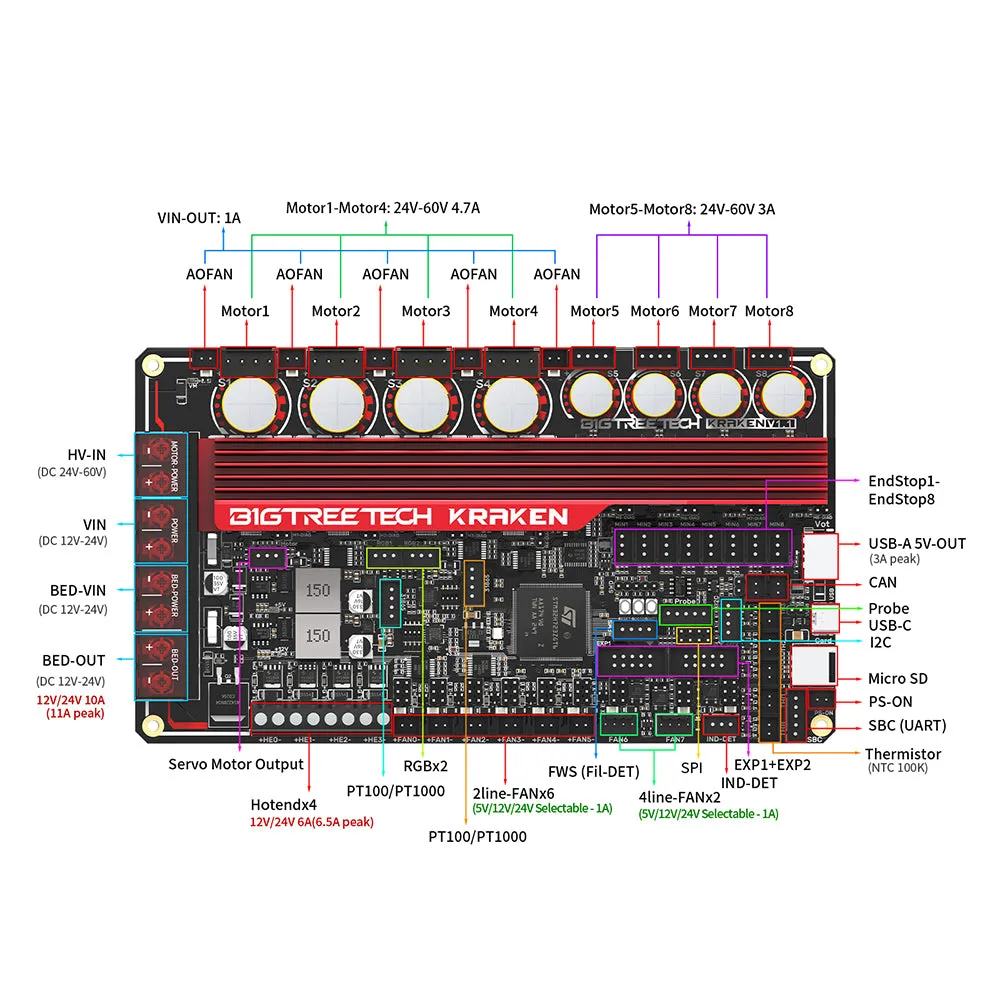
The BIGTREETECH Kraken V1.1 is a 32-bit control board for large 3D printers and projects with many motors. It combines an STM32H723 with eight SPI-controlled TMC2160 drivers, providing a compact electronics platform without eight separate plug-in driver modules.
Its defining feature is the 24 to 60 V HV-IN motor supply. This architecture can be valuable for large CoreXY machines, multiple independent Z motors or systems intended to retain torque at speed. It is not a universal board replacement: the power supplies, motors, wiring, cooling, firmware and load distribution must be designed as one complete system.
Main features
| Item | Documented specification |
|---|---|
| MCU | STM32H723ZGT6, ARM Cortex-M7, published 550 MHz frequency |
| Drivers | 8 integrated TMC2160 drivers, SPI communication |
| Controller supply | DCIN: 12 or 24 V DC |
| Motor supply | HV-IN: 24 to 60 V DC, shared by all eight drivers |
| Bed supply | BED-IN: 12 or 24 V DC |
| Heating | 1 heated-bed output and 4 HE0-HE3 outputs |
| Temperature | 5 100K NTC inputs and 2 MAX31865 channels for PT100/PT1000 |
| Fans | 6 two-pin outputs, 2 four-pin PWM/tachometer outputs and 5 always-on connectors |
| Communications | USB-C, CAN, SBC UART, microSD, I²C, SPI and EXP1/EXP2 |
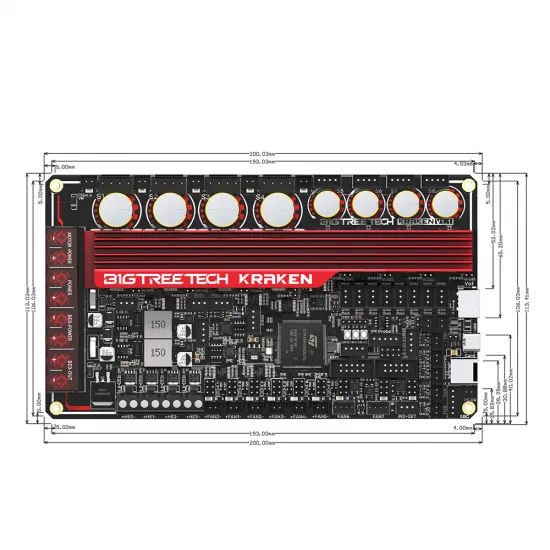
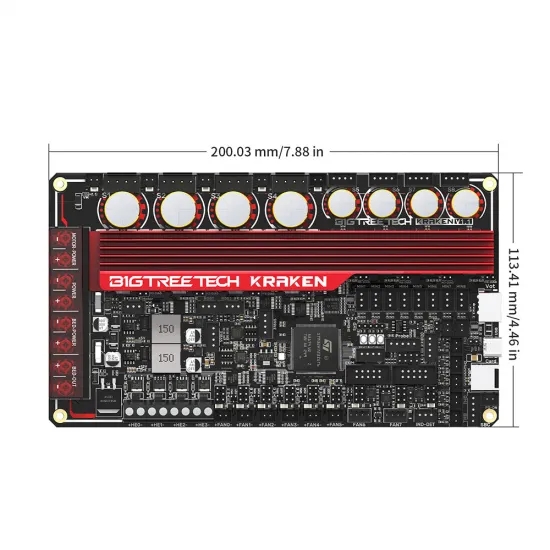
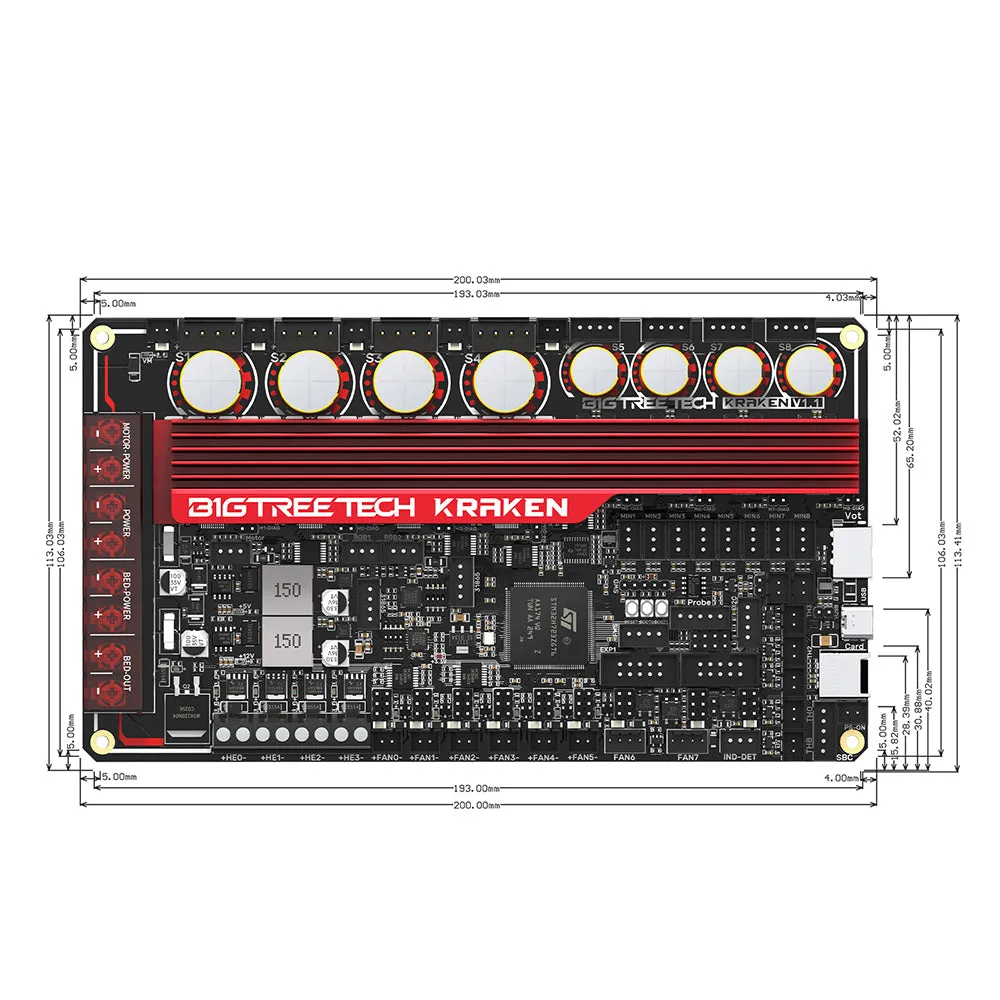
| Dimensions | Approximately 200.03 x 113.41 mm; 193.03 x 106.03 mm mounting centres |
Three power domains
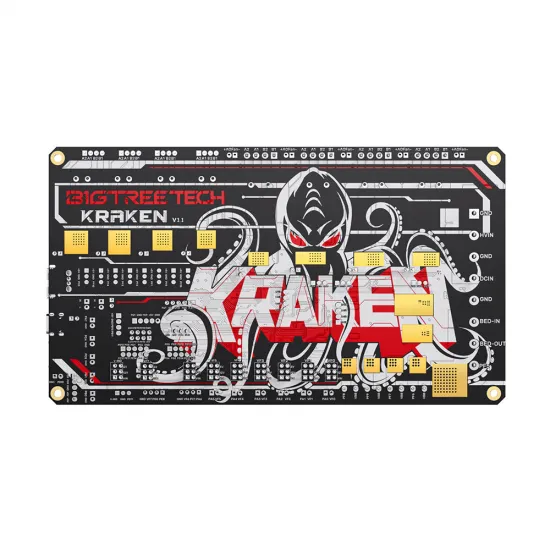
Kraken separates the controller and peripherals, heated bed and motors. This makes it possible to use a 24 V bed with a higher HV motor voltage, but each input must be correctly wired and protected.
- 12/24 V DCIN: powers the controller, its converters and the corresponding auxiliary loads.
- 12/24 V BED-IN: powers the heated-bed branch only.
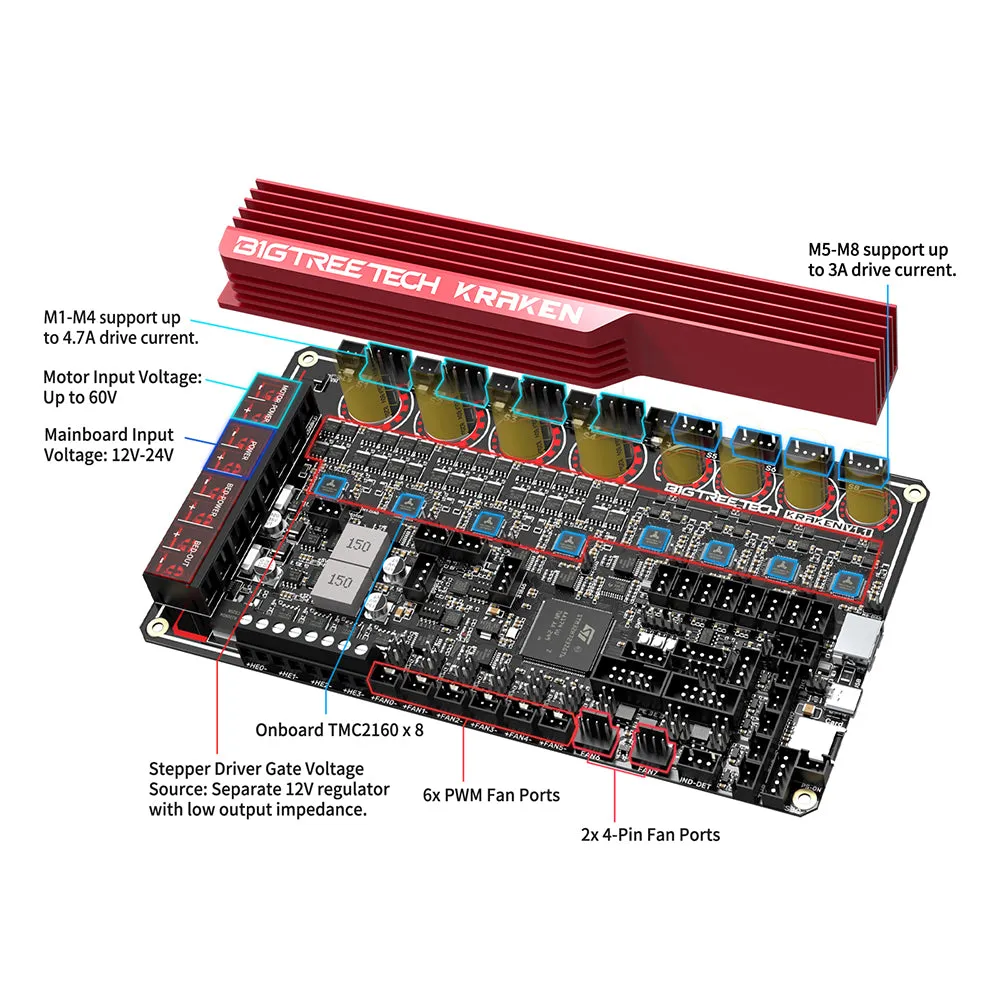
- 24-60 V HV-IN: powers all eight TMC2160 drivers. There is no per-channel motor-voltage selector.
Eight integrated TMC2160 drivers
The TMC2160 drivers provide STEP/DIR motion control with SPI configuration and power stages integrated on the board. BIGTREETECH divides the channels into two groups:
| Channels | V1.1 Rsense | Published maximum | Use criterion |
|---|---|---|---|
| S1-S4 | 0.050 Ω | 4.7 A | Motors needing greater margin, with current set from the motor specification |
| S5-S8 | 0.075 Ω | 3 A | Axes and extruders within motor and cooling limits |
Working current should start from the motor rated current and include thermal margin. Do not configure 4.7 A or 3 A merely because they are the published board maxima. Demanding loads require active heatsink cooling and a prolonged temperature test.
Heaters, fans and sensors
| Output or input | Published capacity | Precaution |
|---|---|---|
| Heated bed | 10 A; 11 A peak | Use a correctly rated external power stage for higher loads |
| HE0-HE3 | 6 A per output; 6.5 A peak | Cartridge heaters and fans must remain below 14 A combined |
| FAN0-FAN7 | 1 A per output; 1.5 A peak | Check the 5/12/24 V selector before connecting each fan |
| TH0-TH3 and TB | 100K NTC with 4.7 kΩ pull-up | The configured thermistor curve must match the actual sensor |
| 2 x MAX31865 | Two- or four-wire PT100/PT1000 | Set DIP switches, wiring and reference: 430 Ω for PT100 or 4300 Ω for PT1000 |
The board also provides eight endstop inputs, DIAG jumpers, probe, servo, filament sensor, PS-ON, RGB and an NPN/PNP proximity-sensor input. Its two CAN connectors are two physical connection points on the same CAN bus, not two independent buses.
Printer and project compatibility
Kraken can be configured for CoreXY, Cartesian, Delta, Kossel, Ultimaker and other kinematics. It is a logical base for projects such as Voron Phoenix, Voron 2.4, Voron Trident or VzBot when the builder needs many motors and verifies the complete design.
Naming a machine does not make the board a drop-in replacement. Check physical space and mounting, BOM and revision, motor count and current, voltages, PSUs, bed, heaters, sensors, endstops, probe, toolboards, connectors and firmware. On a Voron 2.4 or Trident, every Z and A/B motor must be explicitly mapped; never reuse another board's configuration without checking every pin.
A 2.8 A NEMA 23 motor may fall within the range of suitable channels, but this alone does not prove compatibility: voltage, inductance, coil wiring, mechanics, PSU, cooling and configured current must also be suitable.
Klipper configuration
Klipper is a natural match for this board, but the correct hardware revision must be compiled and configured. The documented base uses an STM32H723, a 128 KiB bootloader and a 25 MHz crystal. Communication can be prepared for USB on PA11/PA12 or CAN on PD0/PD1 according to the chosen architecture.
sense_resistor: 0.022 for S1-S4. Kraken V1.1 requires sense_resistor: 0.05 for S1-S4. S5-S8 retain sense_resistor: 0.075.Klipper controls these chips through [tmc5160 ...] sections; this is the register interface used for the TMC2160 and does not mean the physical chip is a TMC5160. Set a motor-specific run_current, do not copy the board maxima, and confirm communication with every driver using DUMP_TMC before commanding motion. Then verify directions and endstops at low speed.
For sensorless homing, fit only the DIAG jumper for the channel in use and calibrate its sensitivity. Remove the corresponding DIAG jumpers when using physical endstops. Example pins, rotation_distance, positions, speeds, PID and sensors must all be adapted to the actual machine.
Marlin configuration
BIGTREETECH originally documented Kraken through BOARD_BTT_KRAKEN_V1_0 and the STM32H723ZG_btt environment. Both the manufacturer's historical branch and the current definition reviewed for this page retain 0.022 Ω for S1-S4, so they must not be compiled unchanged for V1.1.
Marlin therefore requires a source or adaptation that expressly recognises Kraken V1.1 and its 0.050/0.075 Ω sense resistors. Drivers, currents, axes, bed, hotends, thermistors, dimensions, homing and thermal protection must also be configured. Precompiled firmware for another Kraken or another printer is not universal.
RepRapFirmware
BIGTREETECH lists RepRapFirmware support, while the community-maintained TeamGloomy Kraken H723 integration documents the board from RRF 3.5.0-rc.2. This is an advanced community integration, not a universal official image.
For V1.1, its documentation identifies S1-S4 through M569.9 with R0.05 S4.7. Those parameters describe the current-sense stage and its limit; they are not the motor working current. Motor current and axis mapping are configured separately for the machine. This integration also instructs users to remove the DIAG jumpers because it does not use that sensorless-homing method on this platform.
Installation and first power-up
- Confirm that the received board is marked Kraken V1.1.
- Design DCIN, BED-IN and HV-IN separately, using suitable PSUs, fuses and wire sizes.
- Check polarity, terminal torque, protective chassis earth and heatsink airflow.
- Select fan voltages and each PT100/PT1000 input configuration before applying power.
- Leave VUSB open unless USB is deliberately intended to power the controller logic.
- Flash firmware built for STM32H723 and the V1.1 hardware.
- Verify driver communication and plausible room-temperature readings before enabling motors or heaters.
- Test one motor at a time with conservative current and low speed, checking direction, endstop and temperature.
- Test each heater at reduced power and confirm that it affects the corresponding sensor.
- Run a prolonged test while monitoring terminals, PSUs, drivers, heatsink, motors and wiring.
Accessories and expansion
A Klipper system can pair the board with a BIGTREETECH Pi 2 host and a K-Touch network interface. The EBB36 Gen2 and EBB42 Gen2 can act as toolboards in a correctly designed CAN or USB topology. A MicroProbe V2 may be used when its mount, voltage, pinout and configuration are adapted.
If integrated high-current drivers or one shared HV motor supply are unnecessary, the Manta M8P V2.0 provides eight replaceable driver sockets and a different architecture. Choose according to motors, voltage, servicing and host requirements, not merely the number of axes.
This is for you if
- You are designing a large printer with many motors or several independent Z drives.
- You need a 24-60 V motor supply and understand its electrical implications.
- You prefer eight integrated high-performance drivers.
- You will prepare and validate your own firmware and wiring.
- You need many temperature inputs, two MAX31865 channels, CAN and extensive peripherals.
This is not for you if
- You need a configuration-free replacement for your printer's original board.
- Different drivers must operate from different motor-supply voltages.
- You prefer individually replaceable plug-in drivers.
- You cannot provide active cooling and a properly protected HV installation.
- Your machine has few motors and will not use the board's size or capacity.
Package contents
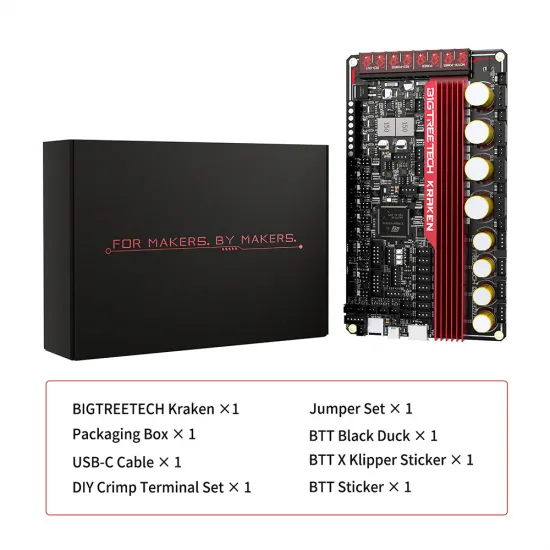
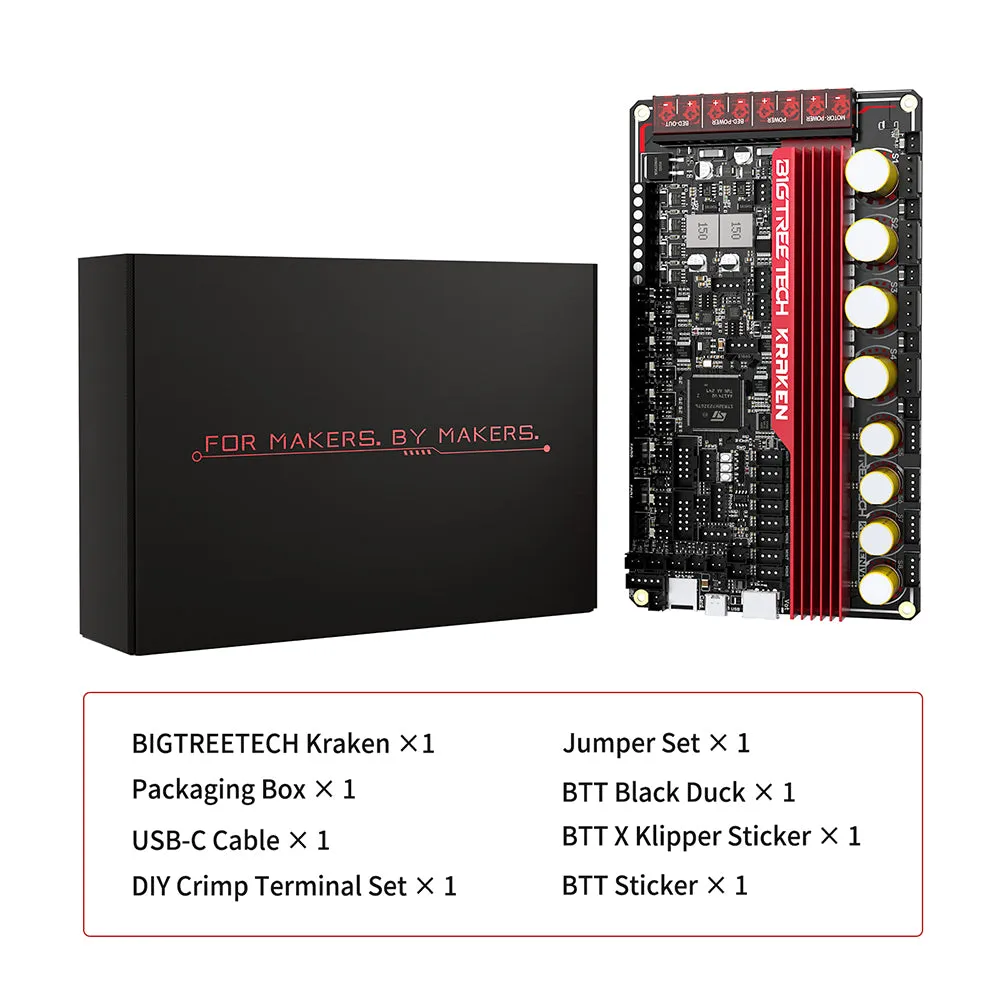
The manufacturer package includes the Kraken V1.1 board, heatsink and fan assembly, wiring and connection accessories shown below. Contents may be updated between batches; check the product image and selector for the supplied presentation.
Refer to the official BIGTREETECH Kraken repository for the manual, pinout, models and firmware files. Always check the hardware revision and document date before reusing a configuration.